The operator's machine


One laptop runs the fleet and the heavy compute.
INSTALL
One command on Linux or macOS
The Workstation runs the same open-source agent as every ADOS profile. Pass the workstation profile on Linux. On macOS the installer builds from source, installs per-user services with no root, and picks the workstation profile for you.
$curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh | sudo bash -s -- --profile workstation$curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh | bashRelease binaries cover 64-bit ARM Linux. On x86_64 Linux, build the agent from source and point the installer at the build. The macOS install needs the Rust toolchain and git.
WHAT IT RUNS
Compute for the fleet, on your desk
The Workstation is a full ADOS node with no flight controller, radio or camera pipeline. It pairs, reports status, keeps logs and hosts extensions, and the World Engine turns it into the fleet's heavy-compute half.
A node in your fleet
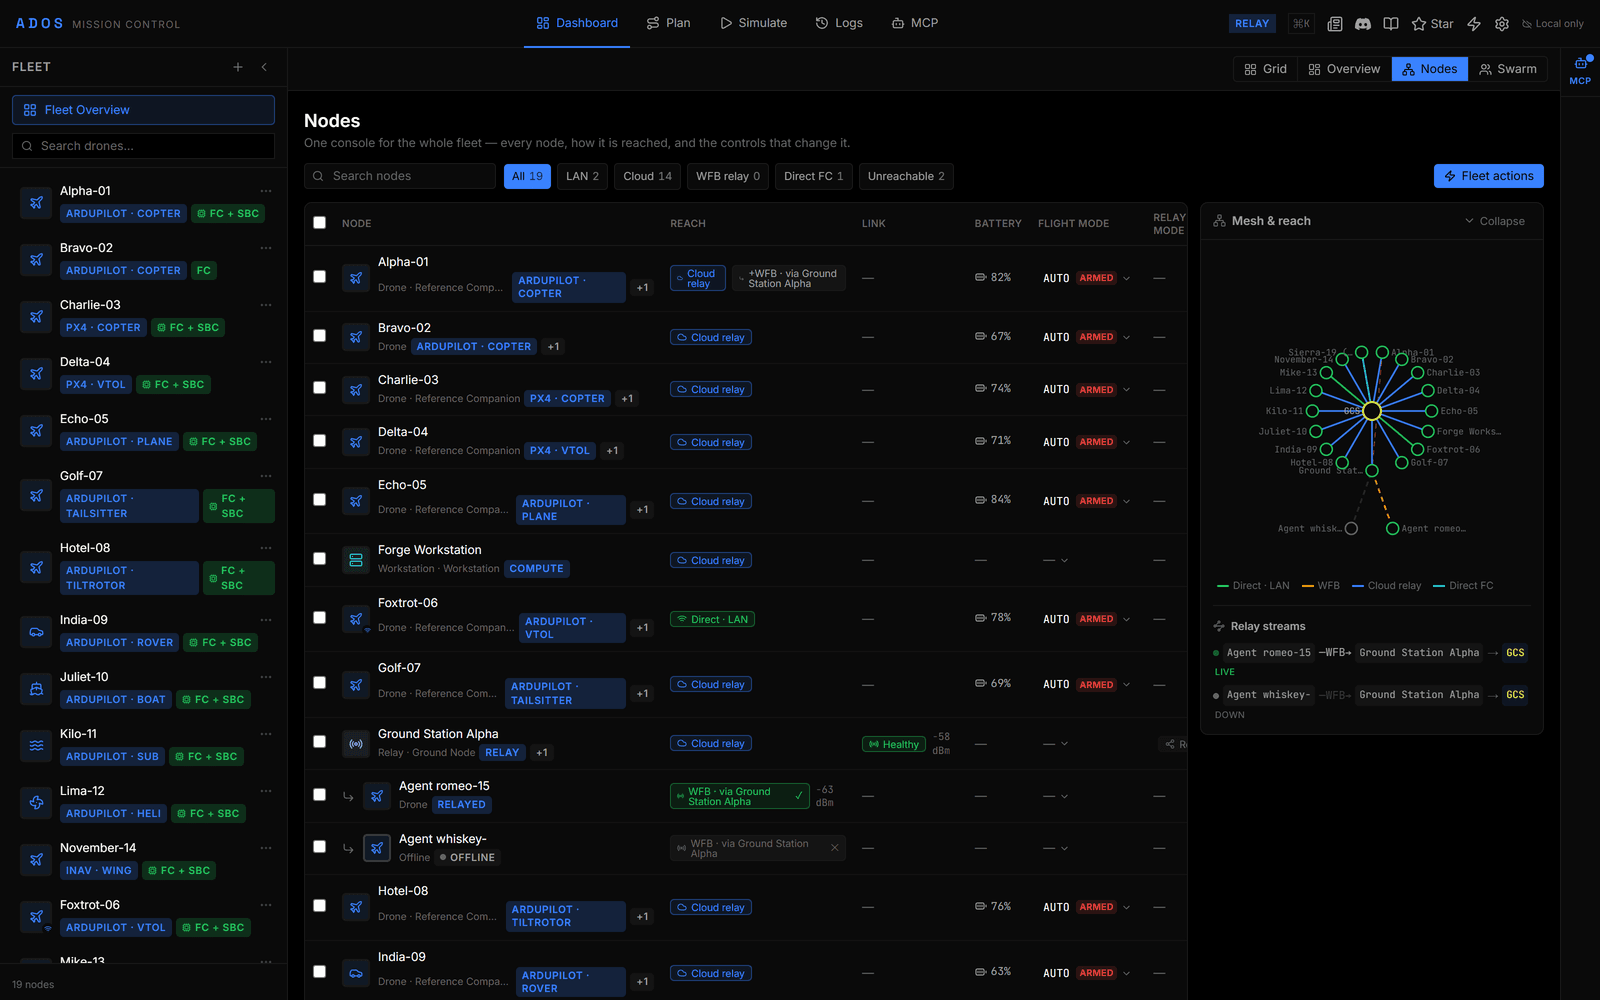
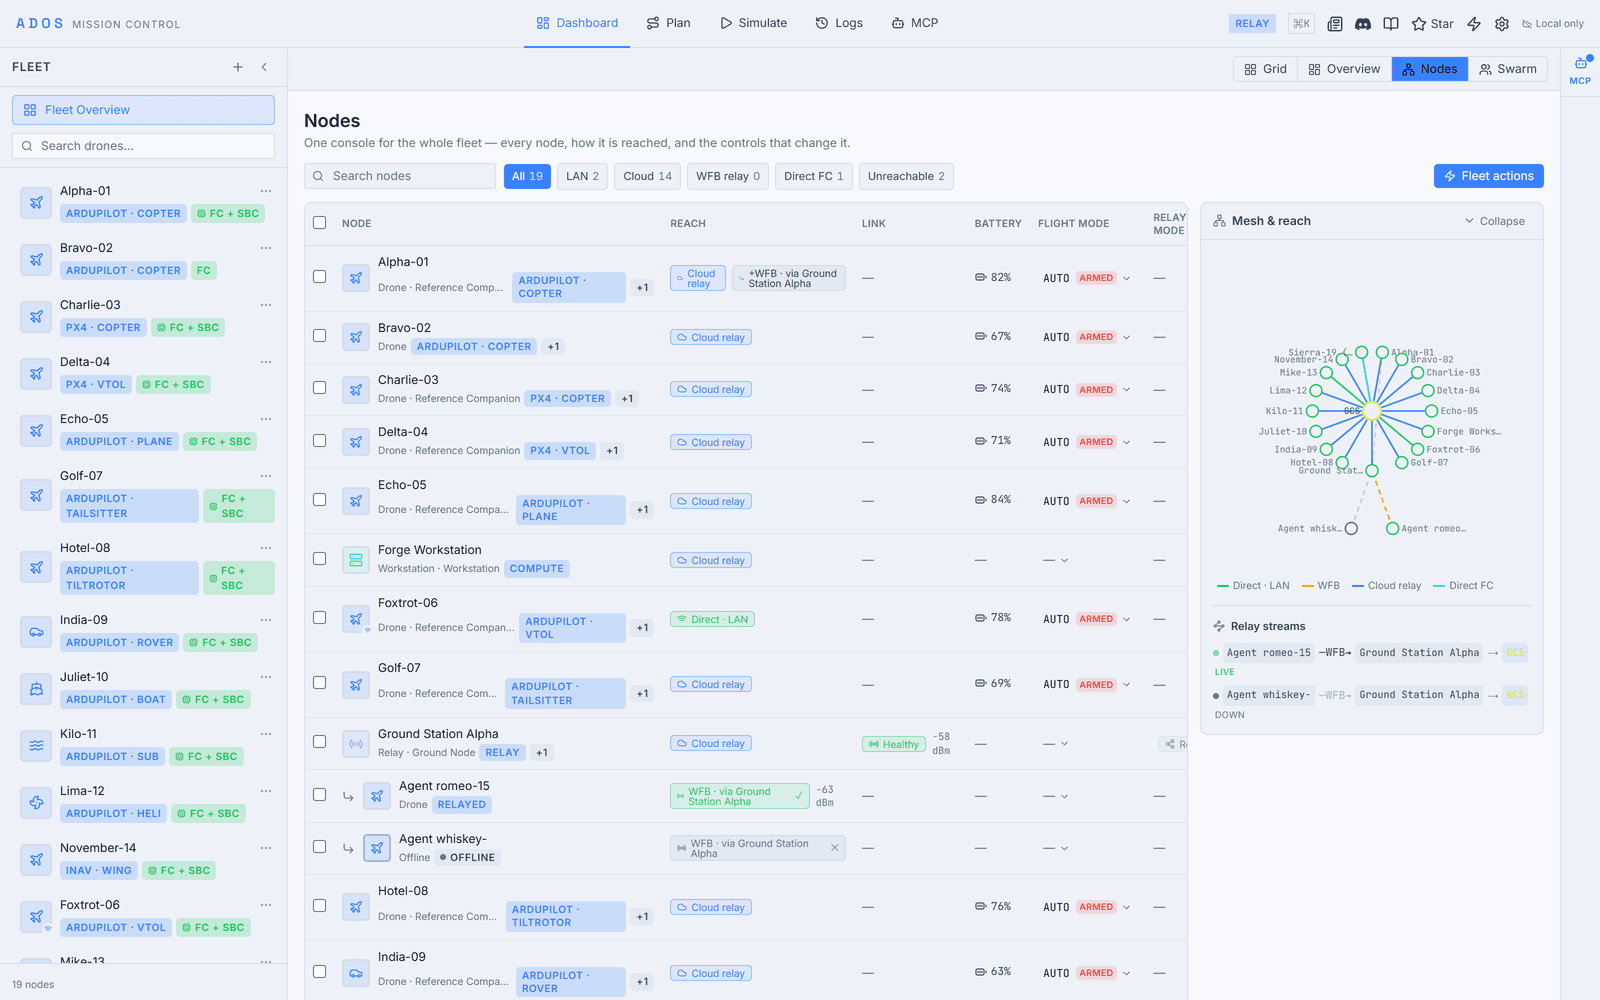
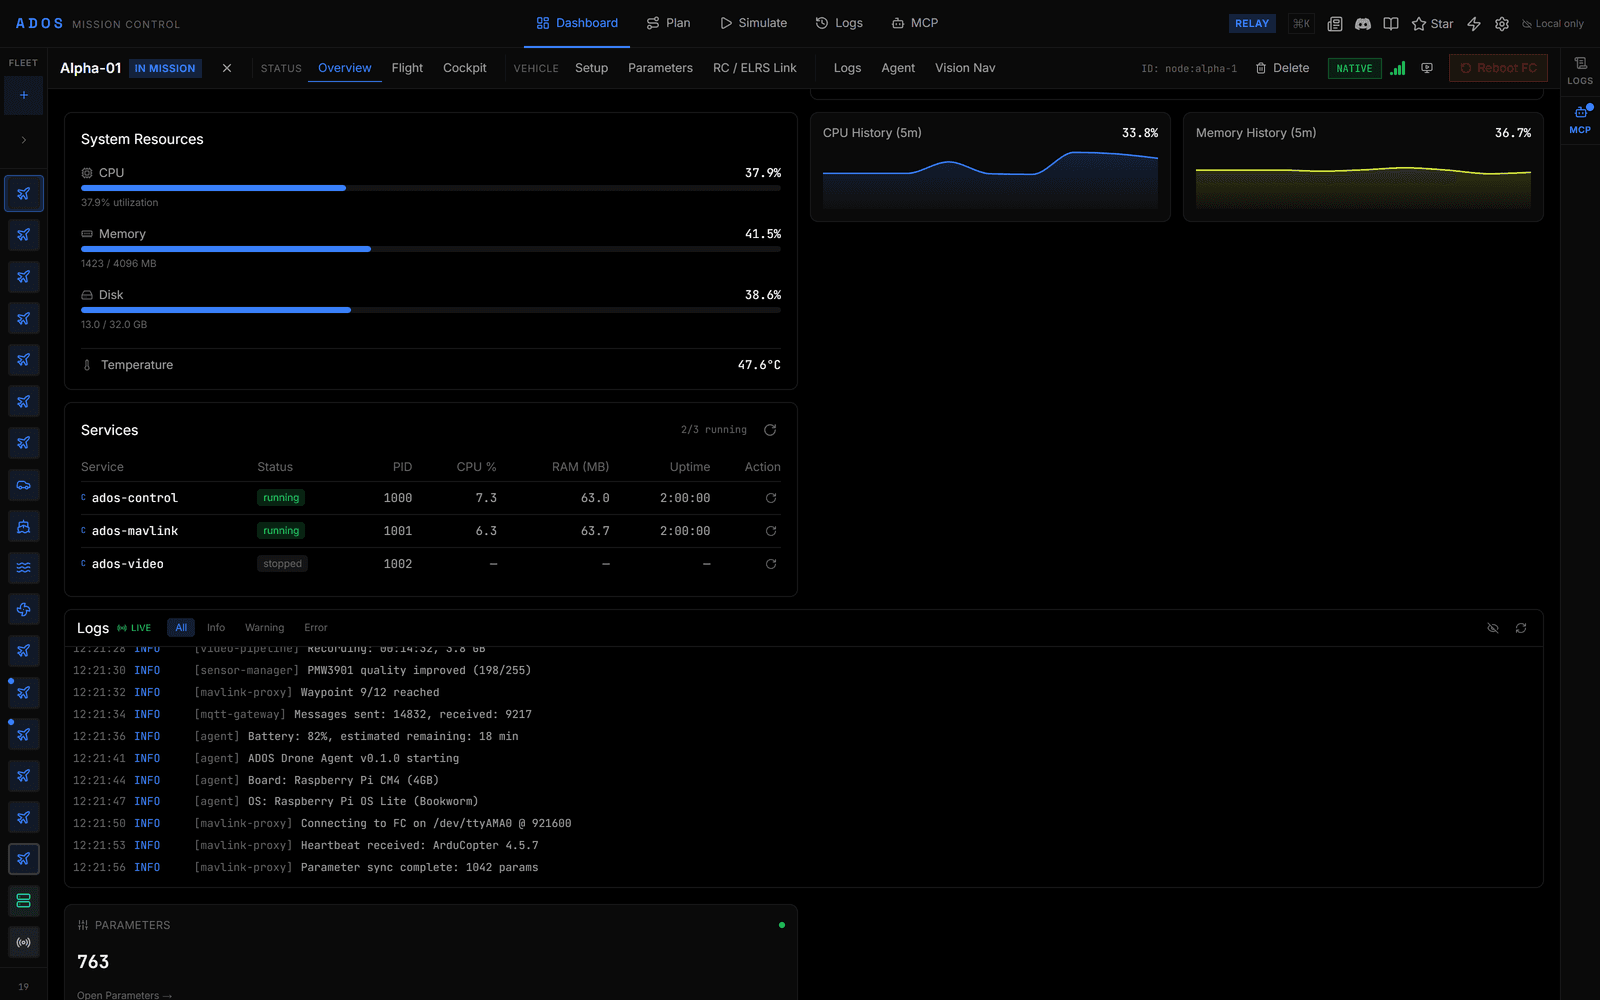
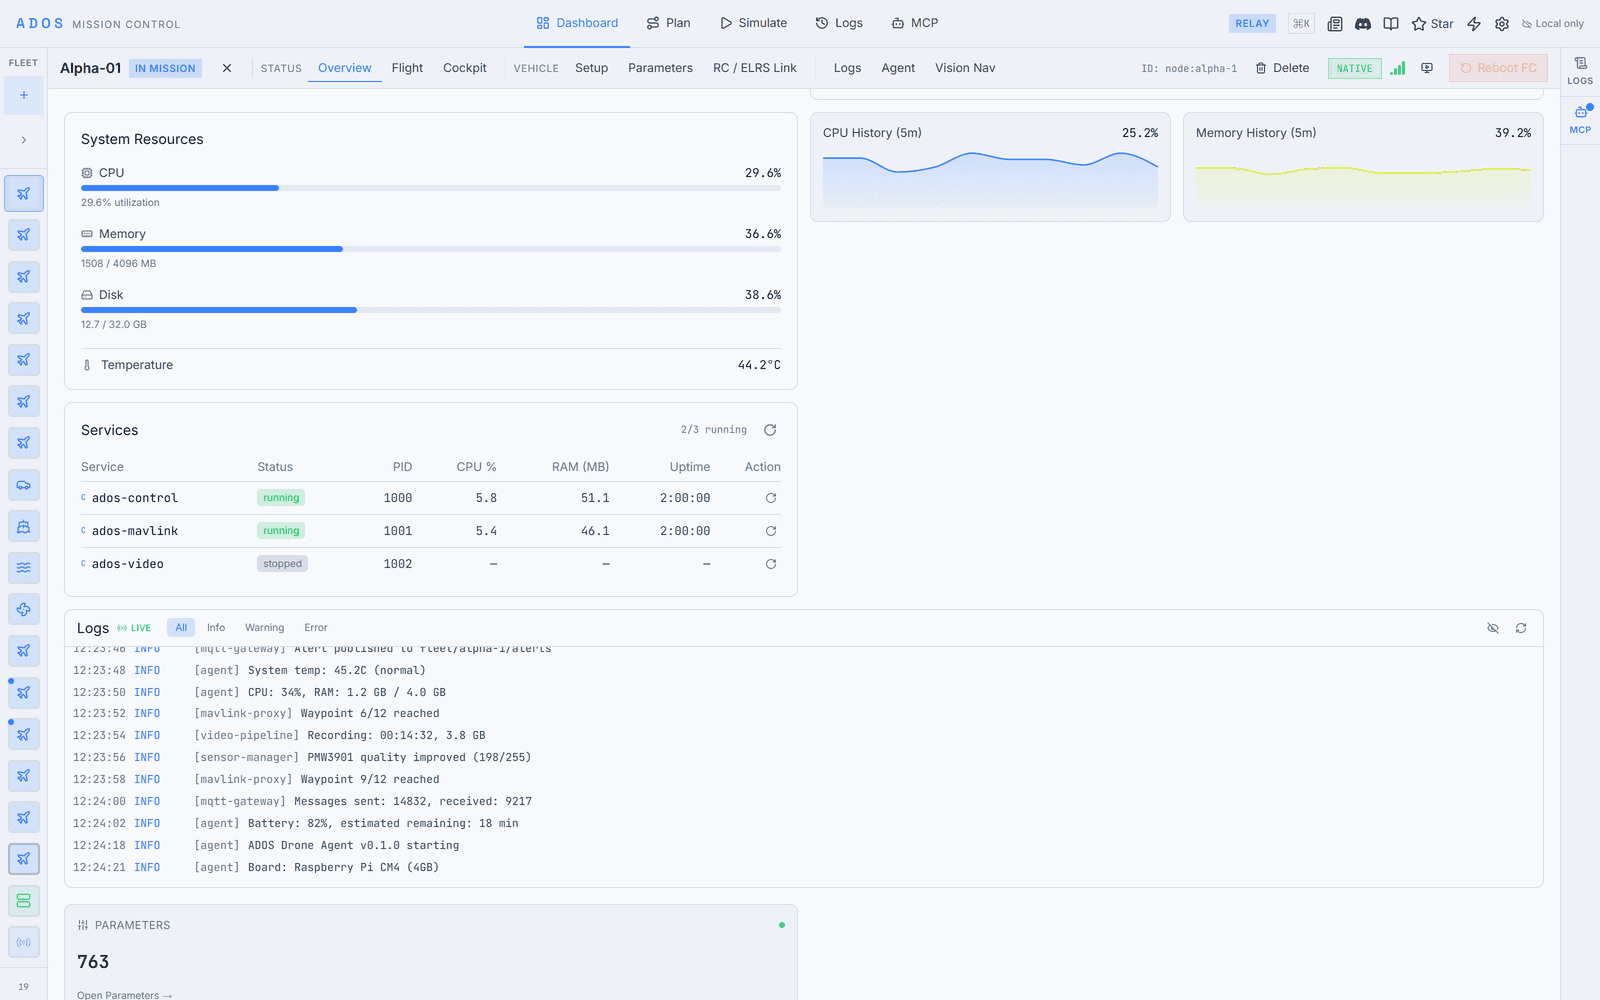
Mission Control lists the Workstation beside your drones and ground stations, with a server icon and a Compute badge. Open it for its status, services, logs and extensions.
World-model reconstruction
Drones send pose-tagged keyframes. The Workstation builds a gaussian splat, point cloud, mesh and occupancy grid, sped up by an NVIDIA or Apple Silicon GPU.
Perception offload
A drone without an accelerator streams its camera here. The Workstation runs the detector and sends detections back to the drone's own detection bus.
Reached by drones, three ways
Keyframes arrive over the LAN first, then through a ground station relaying the radio link, then through the cloud relay.
Mission Control on the same box
Run Mission Control on the Workstation and connect to drones over UDP, TCP or through a ground station on the long-range video and telemetry link.
Extensions, same model
Extensions install on the Workstation through the same plugin host as every node. Other extensions can subscribe to the world model through a declared capability.
TOPOLOGY
The compute hub for the fleet
Drones push keyframes and camera streams to the Workstation, a ground station can relay the capture lane when no shared network reaches the drone, and extra compute nodes are designed to join it as workers.
SPEC
On the Workstation
- Compute
- World Engine node service, job API on port 8092
- Reconstruction
- Splat, point cloud, mesh, occupancy
- Operating systems
- Linux, macOS
- Detector
- ONNX on the Apple GPU (macOS); ONNX source build on Linux
- Not on this profile
- Flight controller link, long-range radio, camera pipeline
- Cluster role
- Master
- License
- GPLv3, open source
EXPLORE
Inside the Workstation
FAQ
Frequently asked questions
What is ADOS?
ADOS is Altnautica's drone operating stack: the software layers that run across the drone, the ground, and the cloud. It is open source under GPLv3, works with ArduPilot, PX4, Betaflight, and iNav, and runs on hardware you already own.
Does Altnautica need the internet or the cloud?
No. The platform is local-first. Mission Control reaches a drone directly over the local network, and the drone-to-ground link is a local radio. Cloud fleet management through MeshNet is an optional layer for remote access and analytics.
Is Altnautica free and open source?
Yes. Mission Control, the drone agent, the ground agent, and the workstation are free and open source under GPLv3, and the MCP server is MIT. There is no paid edition and no locked features.
Run the heavy compute on your own machine
The Workstation profile installs from the same open-source agent, licensed GPLv3.
Read the docs