The software-defined drone stack


Aircraft, ground station, laptop and cloud, one platform.
Architecture
One stack, four layers
From the board on the drone up to the fleet in the cloud. Every layer is independent, and every layer is open.
Capabilities
Every part of the platform
Compute, autonomy, connectivity, and the ecosystem around them, plus the three surfaces you run them from. Each page says plainly what ships today and what is still in development.
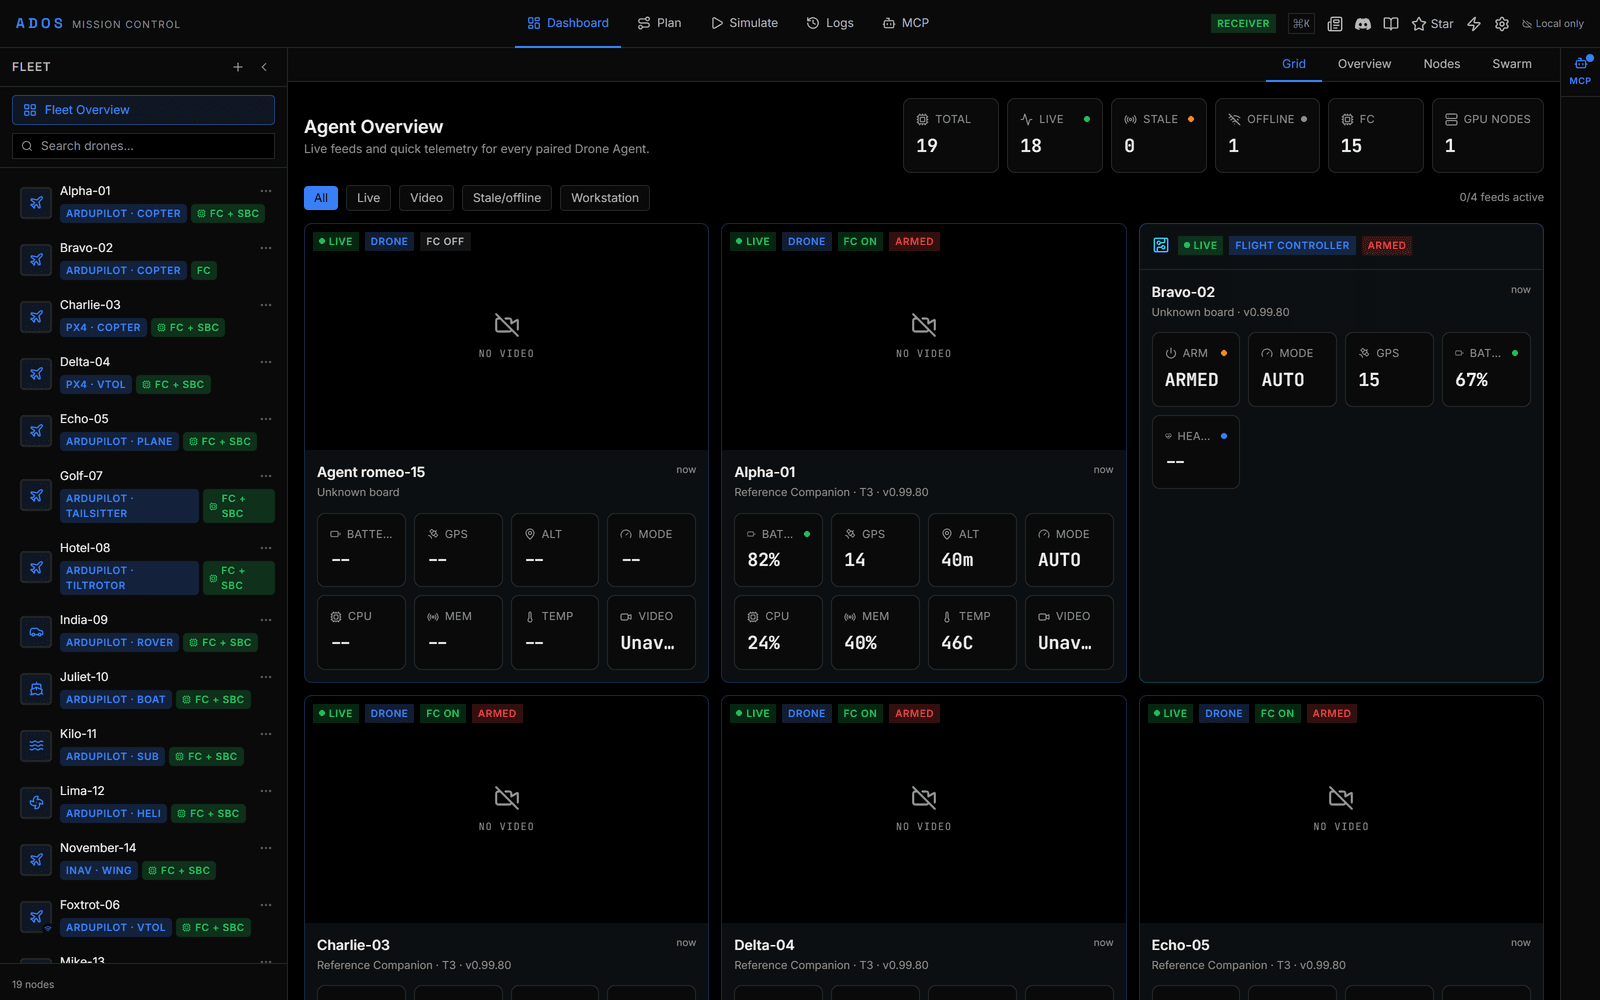
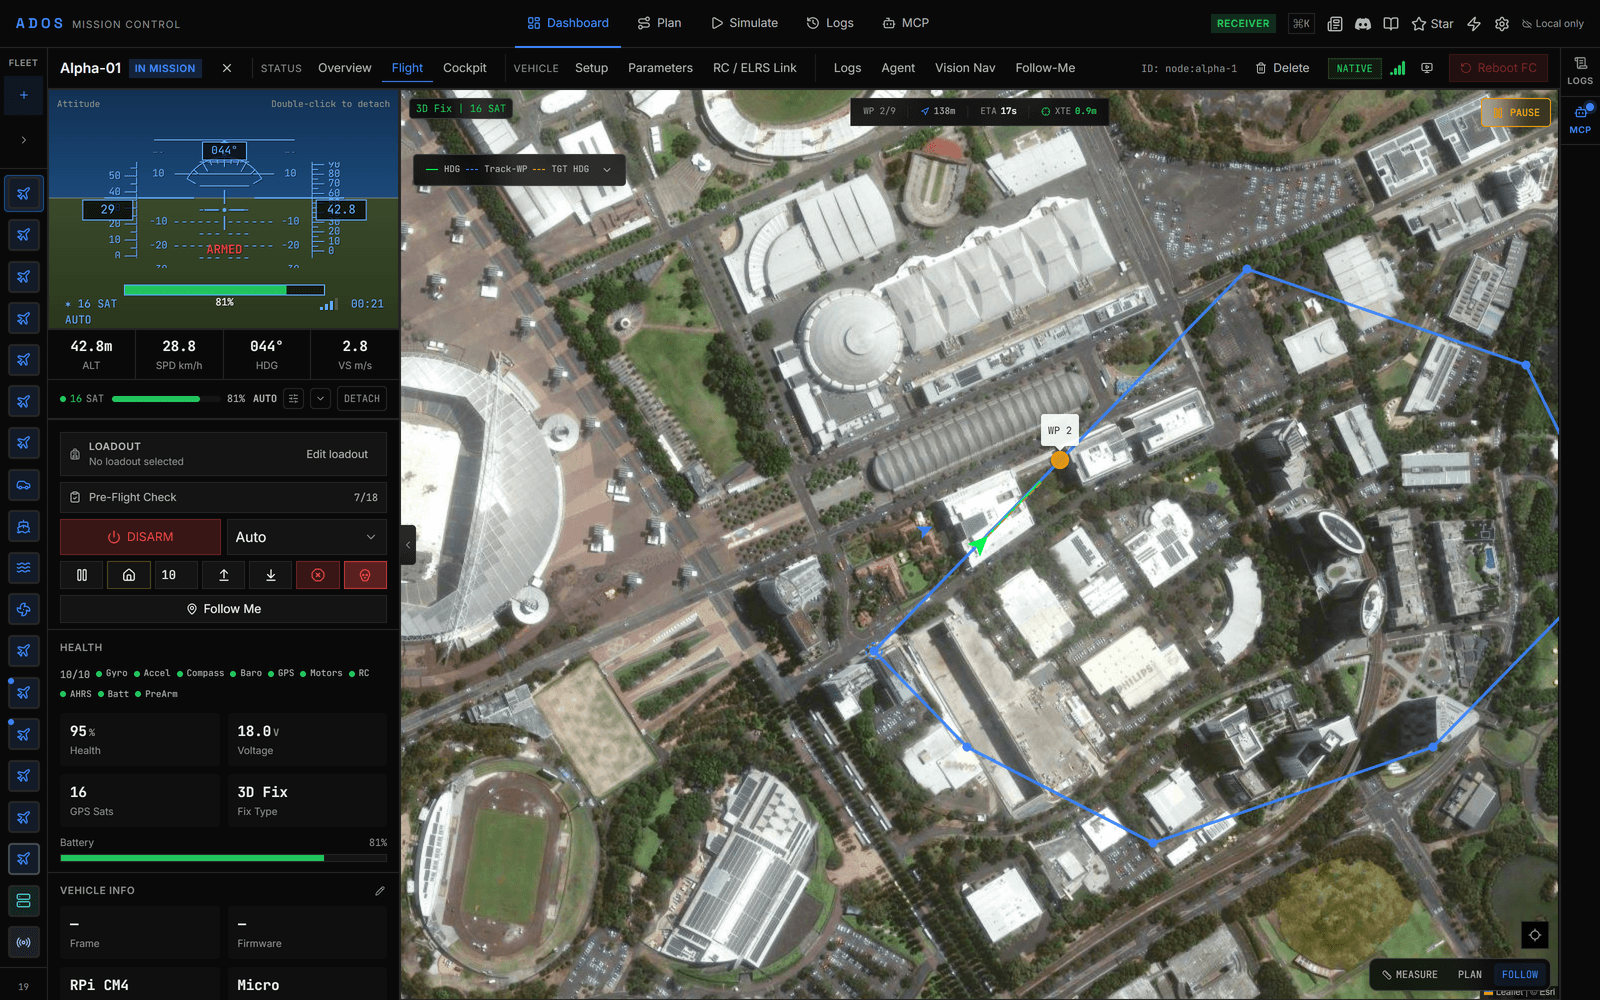
Mission Control
The browser ground station: fleet dashboard, flight control, and configuration.
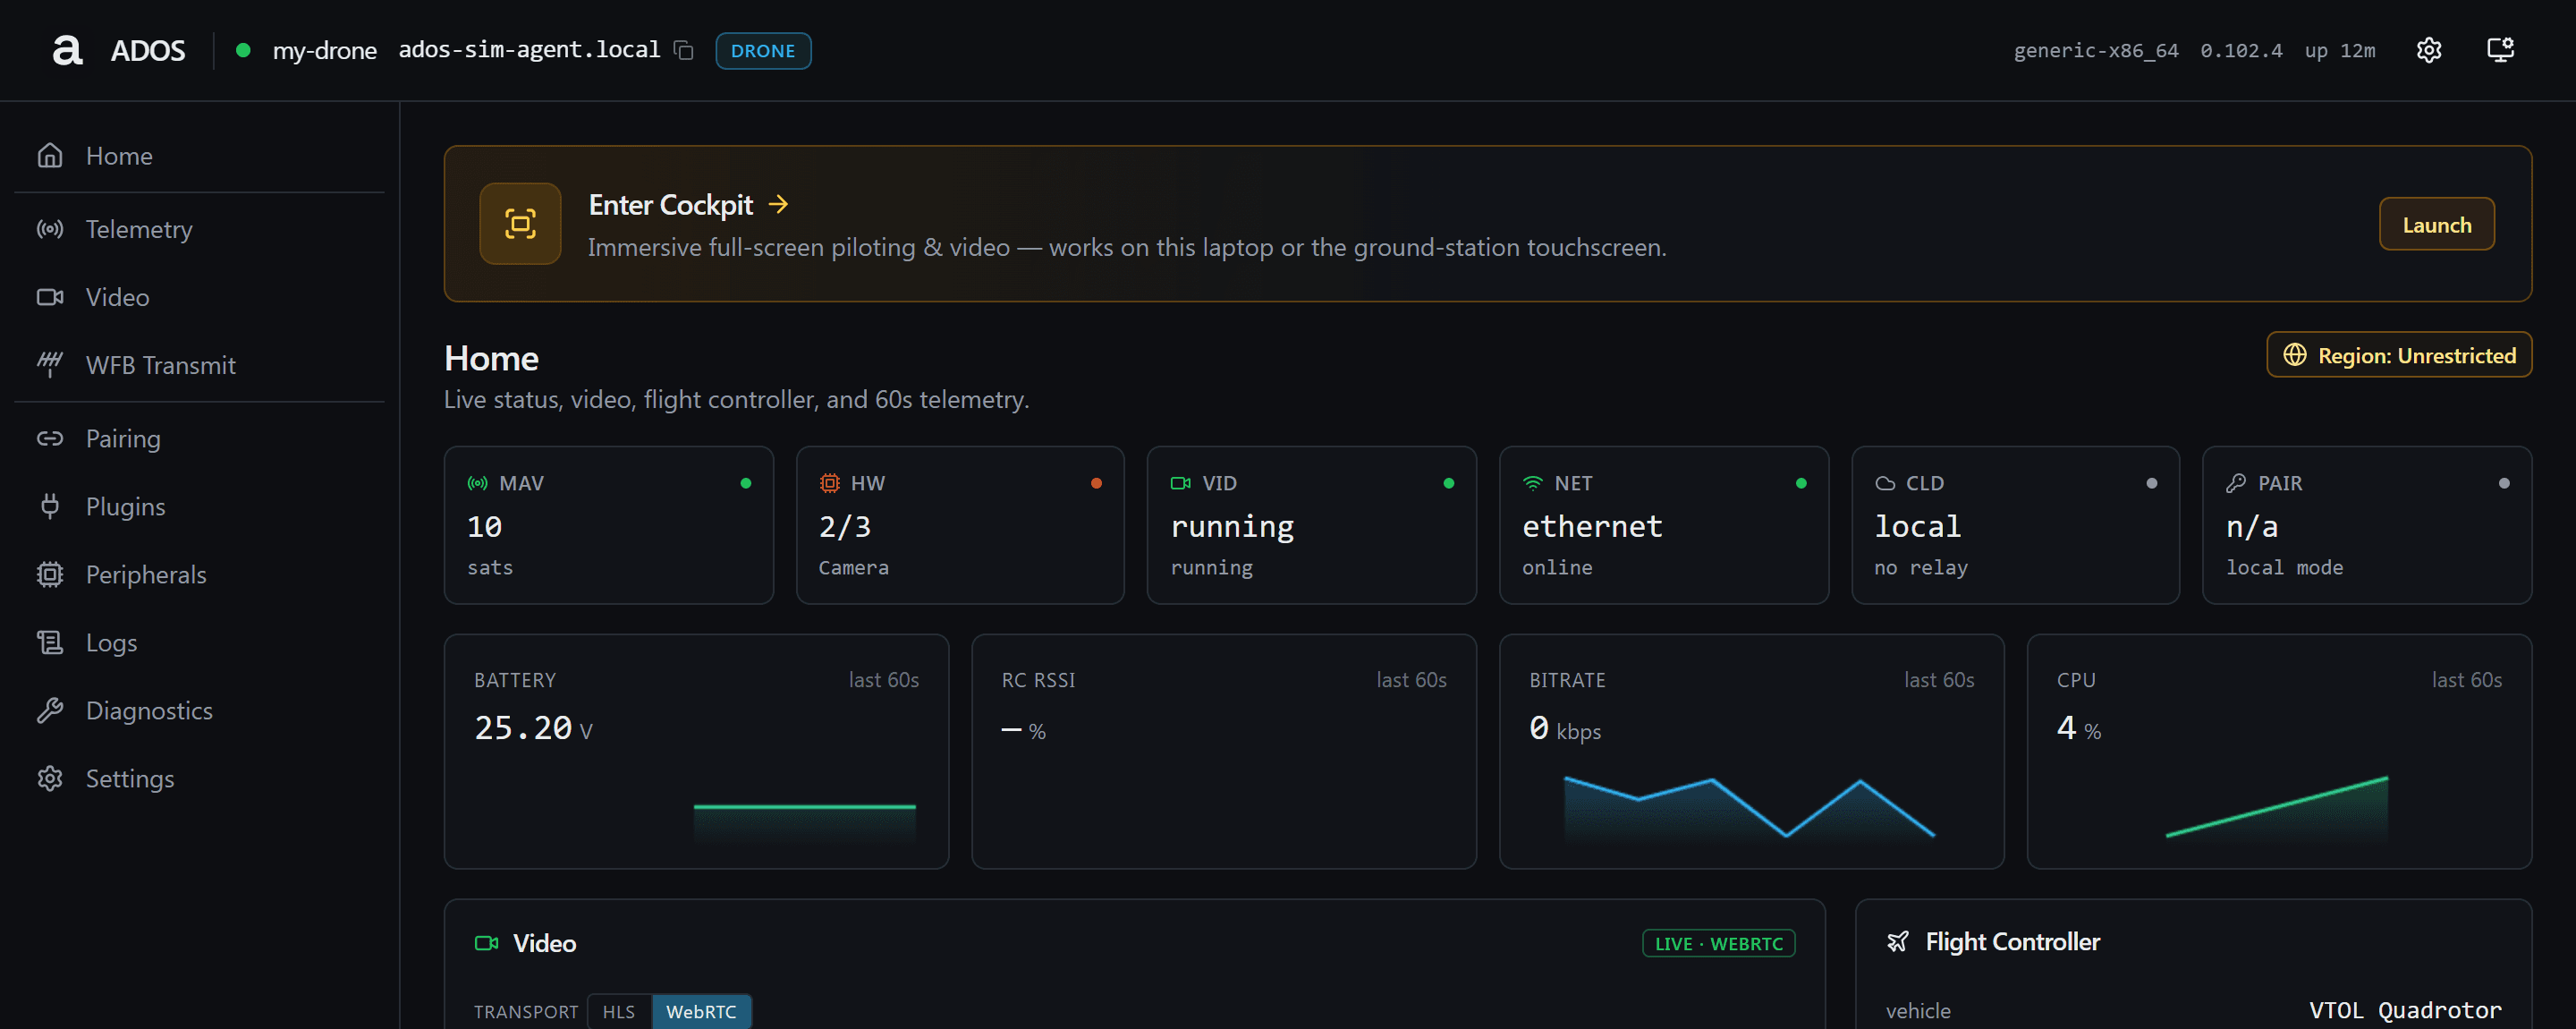
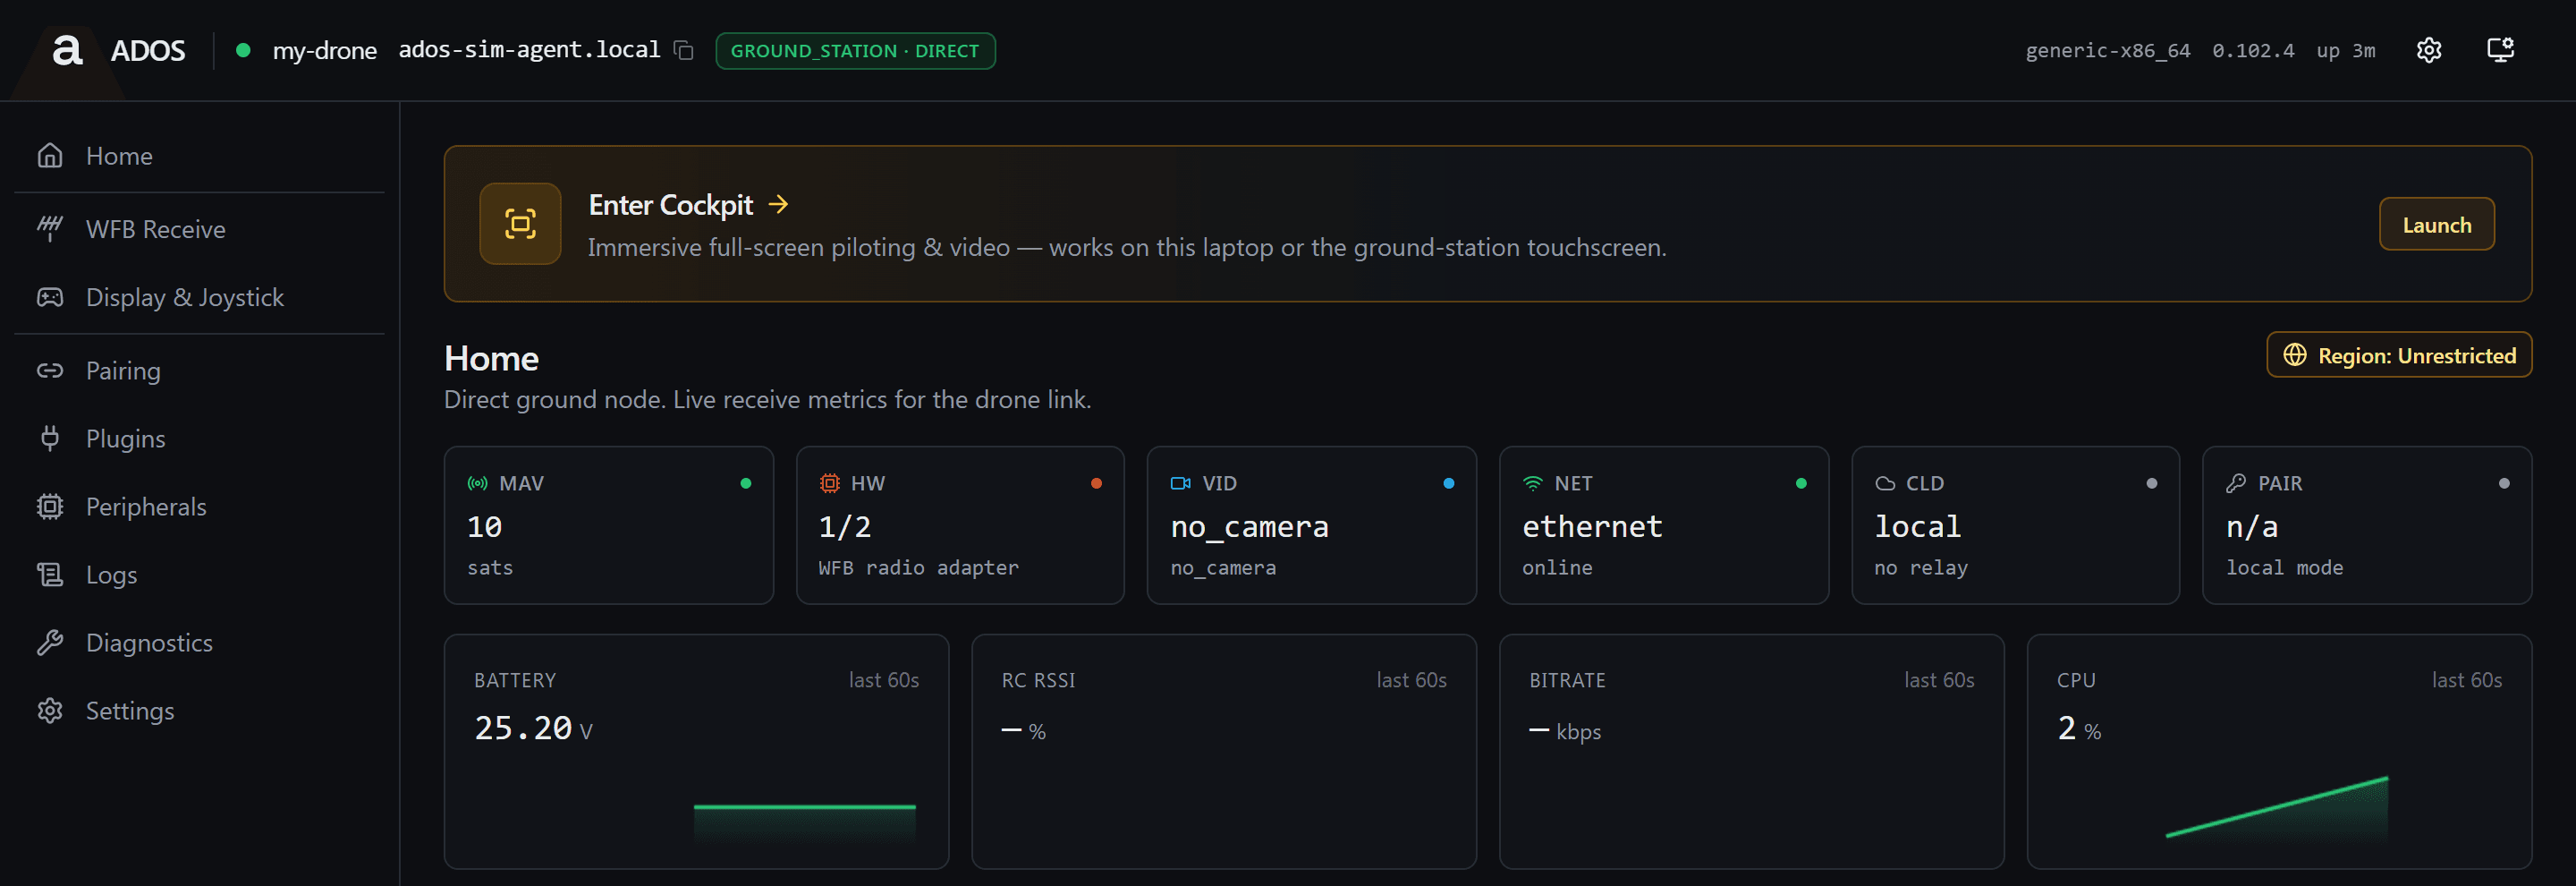
Drone Agent
The agent on the companion computer, with its own status page served from the drone.
Ground Agent
The same agent in its ground station profile, with a status page of its own.
Flight Computer
AI compute, flight control, video, and 4G LTE on one board
Learn moreVision Engine
Model registry, custom model upload, and on-vehicle inference
Learn moreSensor Fusion
Multi-sensor fusion hub design for the companion computer
Learn moreAtlas
Capture-to-reconstruction world model: splats, point clouds, mesh
Learn moreVideo & Data Link
HD video rated to 50 km line of sight, diversity receive, WebRTC cloud relay
Learn moreMeshNet
Cloud fleet telemetry, MQTT relay, four agent capability tiers
Learn moreSwarm
Fleet coordination: the swarm bus and on-board swarm logic
Learn moreLoRa
Long-range low-throughput link and mesh reach across the fleet
Learn moreSurvey & 3D
Plan, capture, and reconstruct; six mission file formats
Learn moreProtocols
Full ArduPilot, PX4, Betaflight, and iNav support
Learn moreExtension System
The extension platform: signed agent plugins and sandboxed GCS panels
Learn morePrinciples
What the platform stands for
One ground station and one agent speak ArduPilot, PX4, Betaflight, and iNav. The agent ships profiles for 19 companion boards, with generic fallbacks for the rest.
GPLv3 software and CC0 hardware. Fork it and ship it commercially. Hardware revisions made under CC0 can stay private.
The ground station reaches an agent directly over the LAN. Cloud relay is there when you want remote reach, never required.
The onboard agent runs a hybrid Rust and Python runtime, with the flight-critical paths written in Rust for reliability.
FAQ
Frequently asked questions
What is ADOS?
ADOS is Altnautica's drone operating stack: the software layers that run across the drone, the ground, and the cloud. It is open source under GPLv3, works with ArduPilot, PX4, Betaflight, and iNav, and runs on hardware you already own.
Which flight-controller firmware does Altnautica support?
Altnautica supports ArduPilot and PX4 fully over MAVLink, and Betaflight and iNav over MSP. The same Mission Control ground station configures and flies all four.
What hardware does the drone agent run on?
The drone agent ships profiles for 19 companion boards, plus generic ARM64 and x86_64 fallbacks, from a Raspberry Pi 3, 4, and 5 and Compute Modules to NVIDIA Jetson Nano and Orin Nano, Radxa, Orange Pi, BeagleBoard, and other ARM64 Linux boards. One install command detects the board and configures it.
One ecosystem for any drone
Start with the ground station in your browser, then add the agent to any companion computer.
Launch Mission Control