Make any drone autonomous.
An open-source, software-defined drone platform: one ecosystem for the companion computer, the ground station, ground control and the fleet cloud.
Plan, fly and configure in the browser. Works with ArduPilot, PX4, Betaflight and iNav.
Open Mission ControlOne install on the companion computer. It detects the board and runs only the services that board can carry.
curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh | sudo bashcurl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh | sudo bash -s -- --profile ground-stationSigned plugins add hardware, sensors and flight behaviors to the agent, and panels to Mission Control.
ados plugin install ./my-plugin.signed.adosplug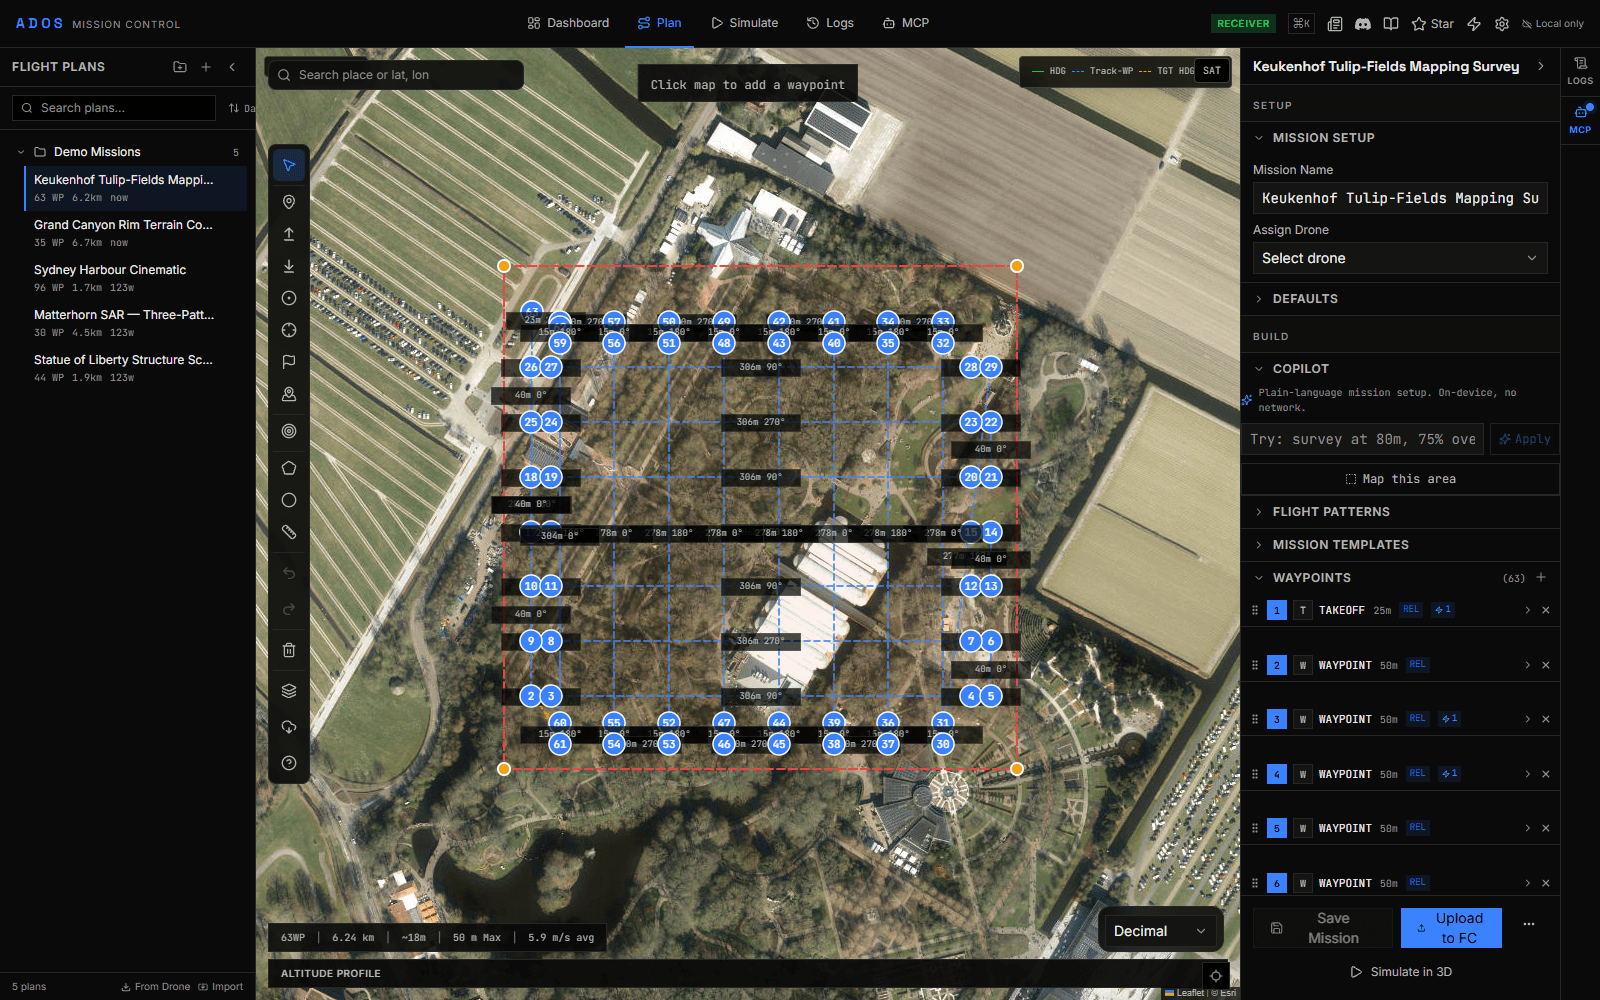
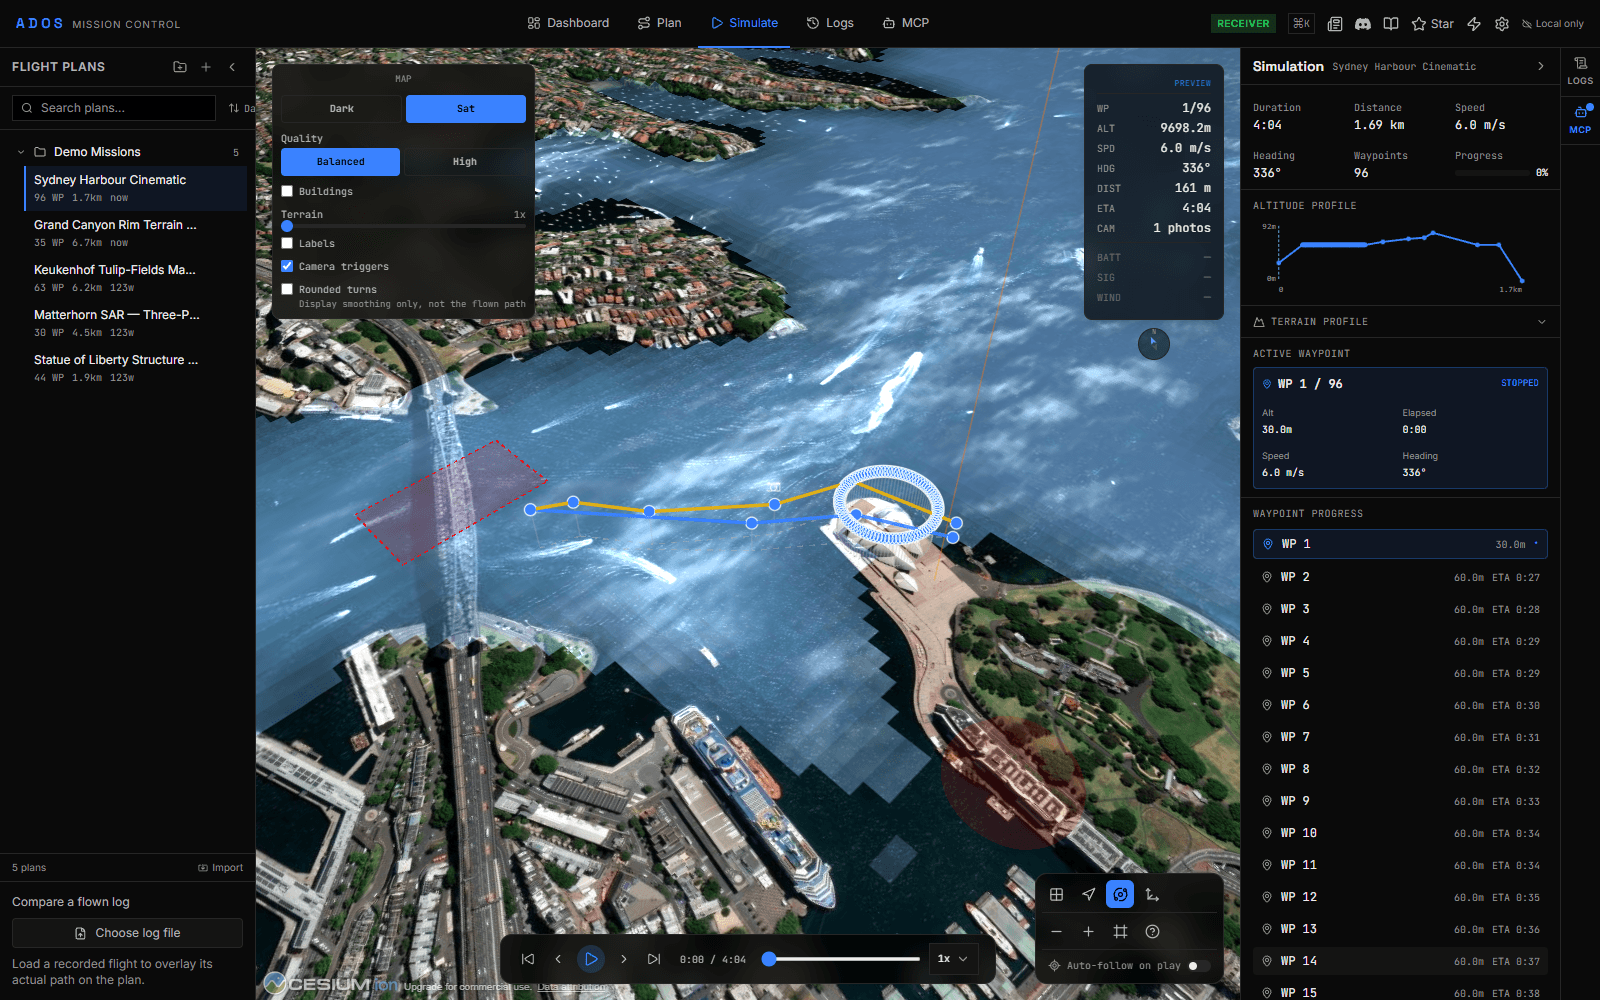
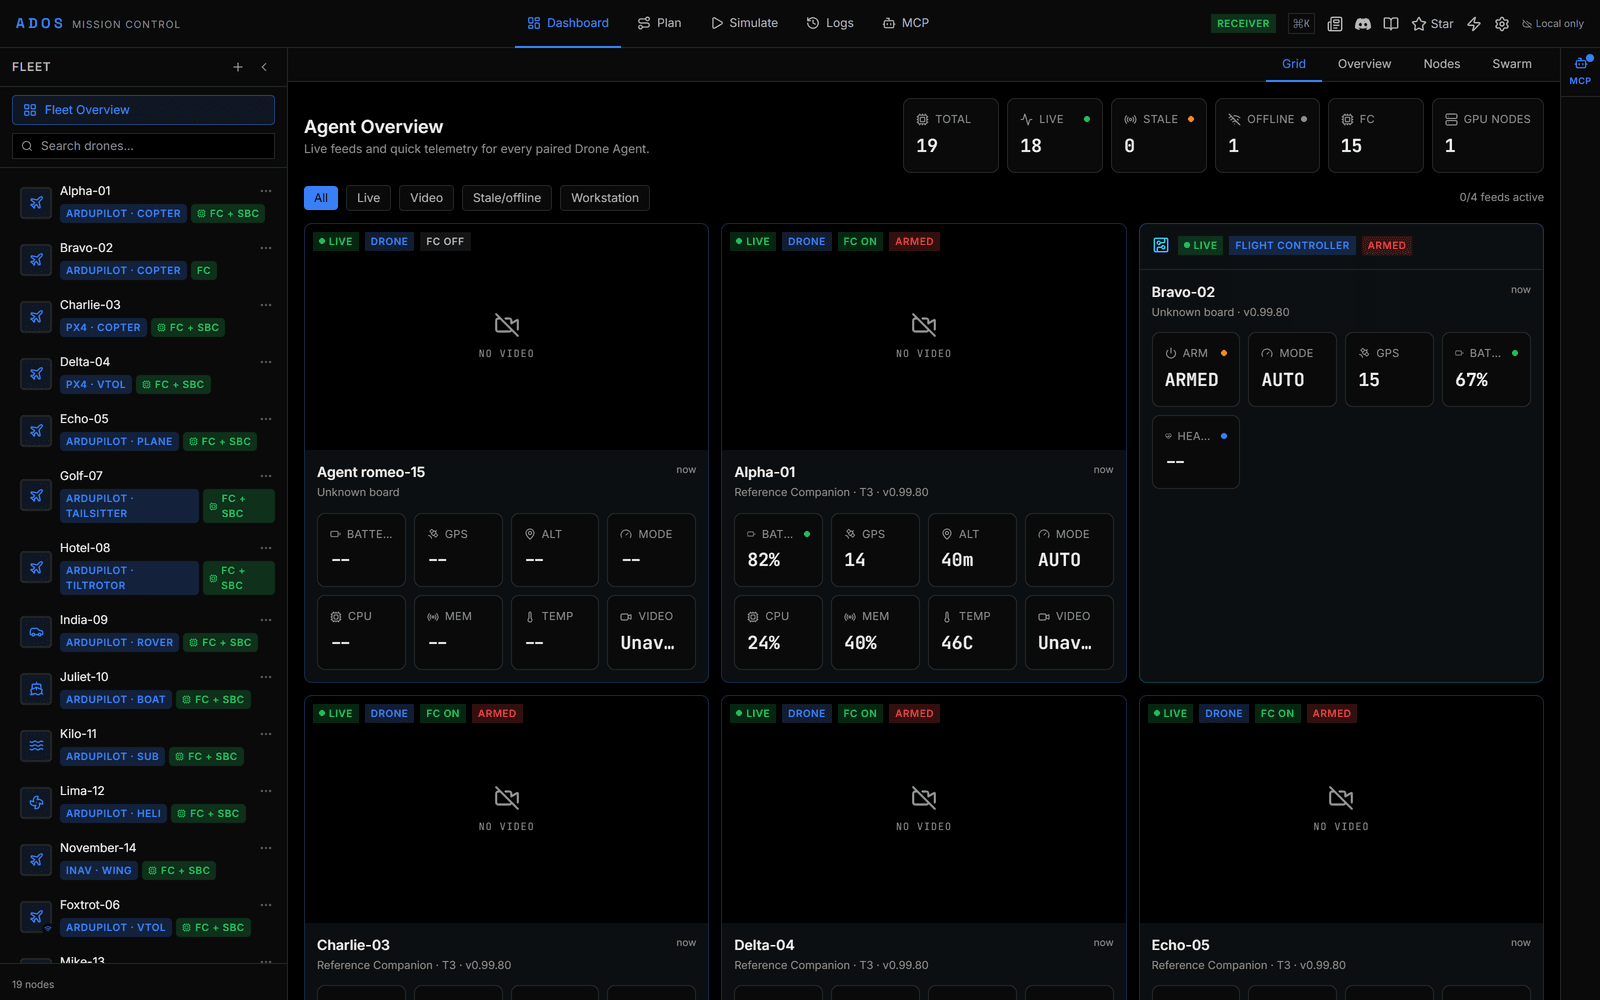
Mission ControlPlan survey grids, search patterns and waypoint routes on a real map, with terrain-relative altitudes.
THE PRODUCTS
Four agent profiles. One ground station. Any drone.
Every profile runs the same codebase and speaks the same protocols. Run one, or run them together as a fleet.
Ground Control
Mission Control
Browser ground station with fleet telemetry, mission planning, 3D simulation, the parameter editor, and an immersive cockpit.
Learn more →Onboard
Drone Agent
Software-defined companion for the flight controller. MAVLink proxy, video pipeline, one-command updates, cloud relay, and Python or Rust plugins.
Learn more →Ground Station
Ground Agent
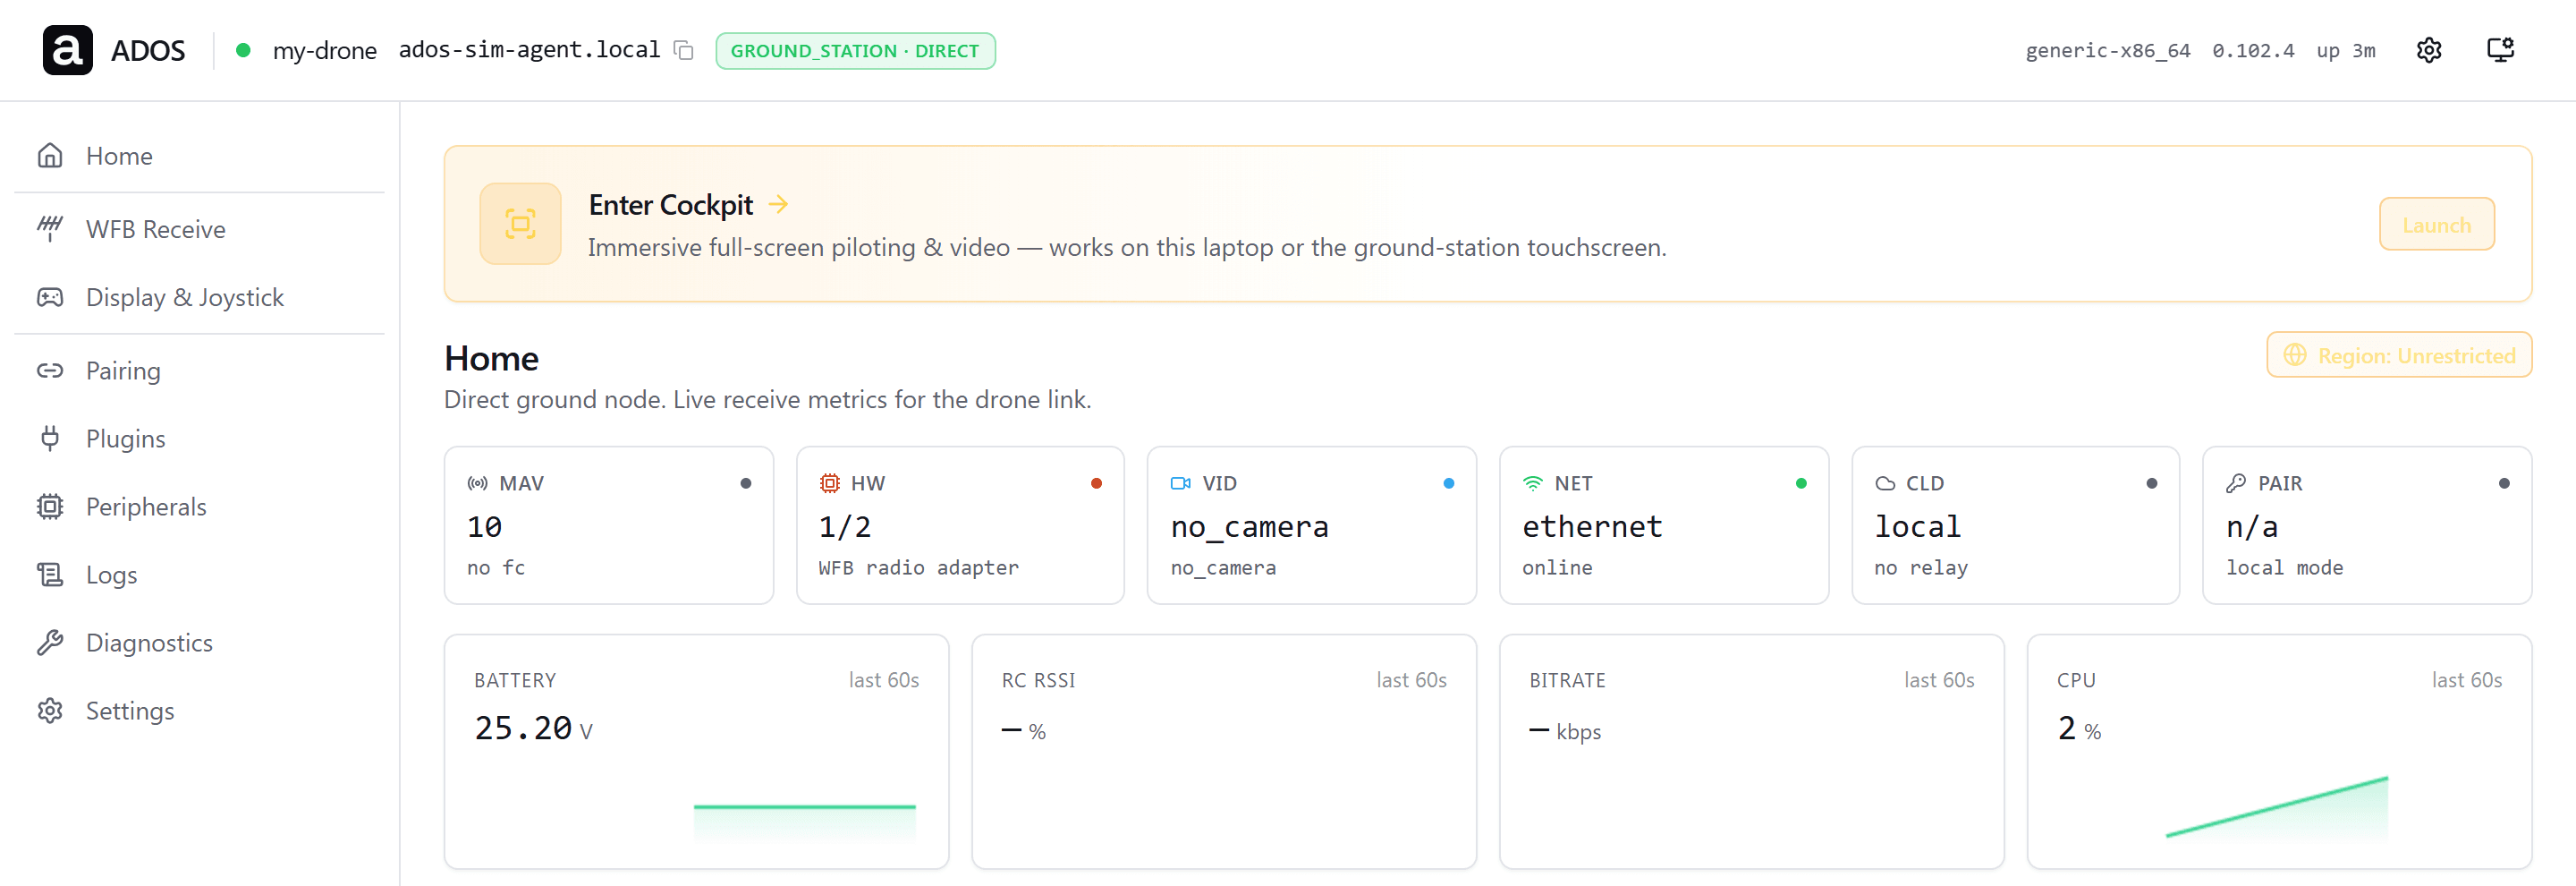
The ground side of the radio pair. Distributed receive, self-healing mesh, the full uplink matrix, and a physical UI.
Learn more →Compute
Workstation
The operator's machine: GPU compute for reconstruction and perception offload, plus pairing, logs, and extensions, on one profile.
Learn more →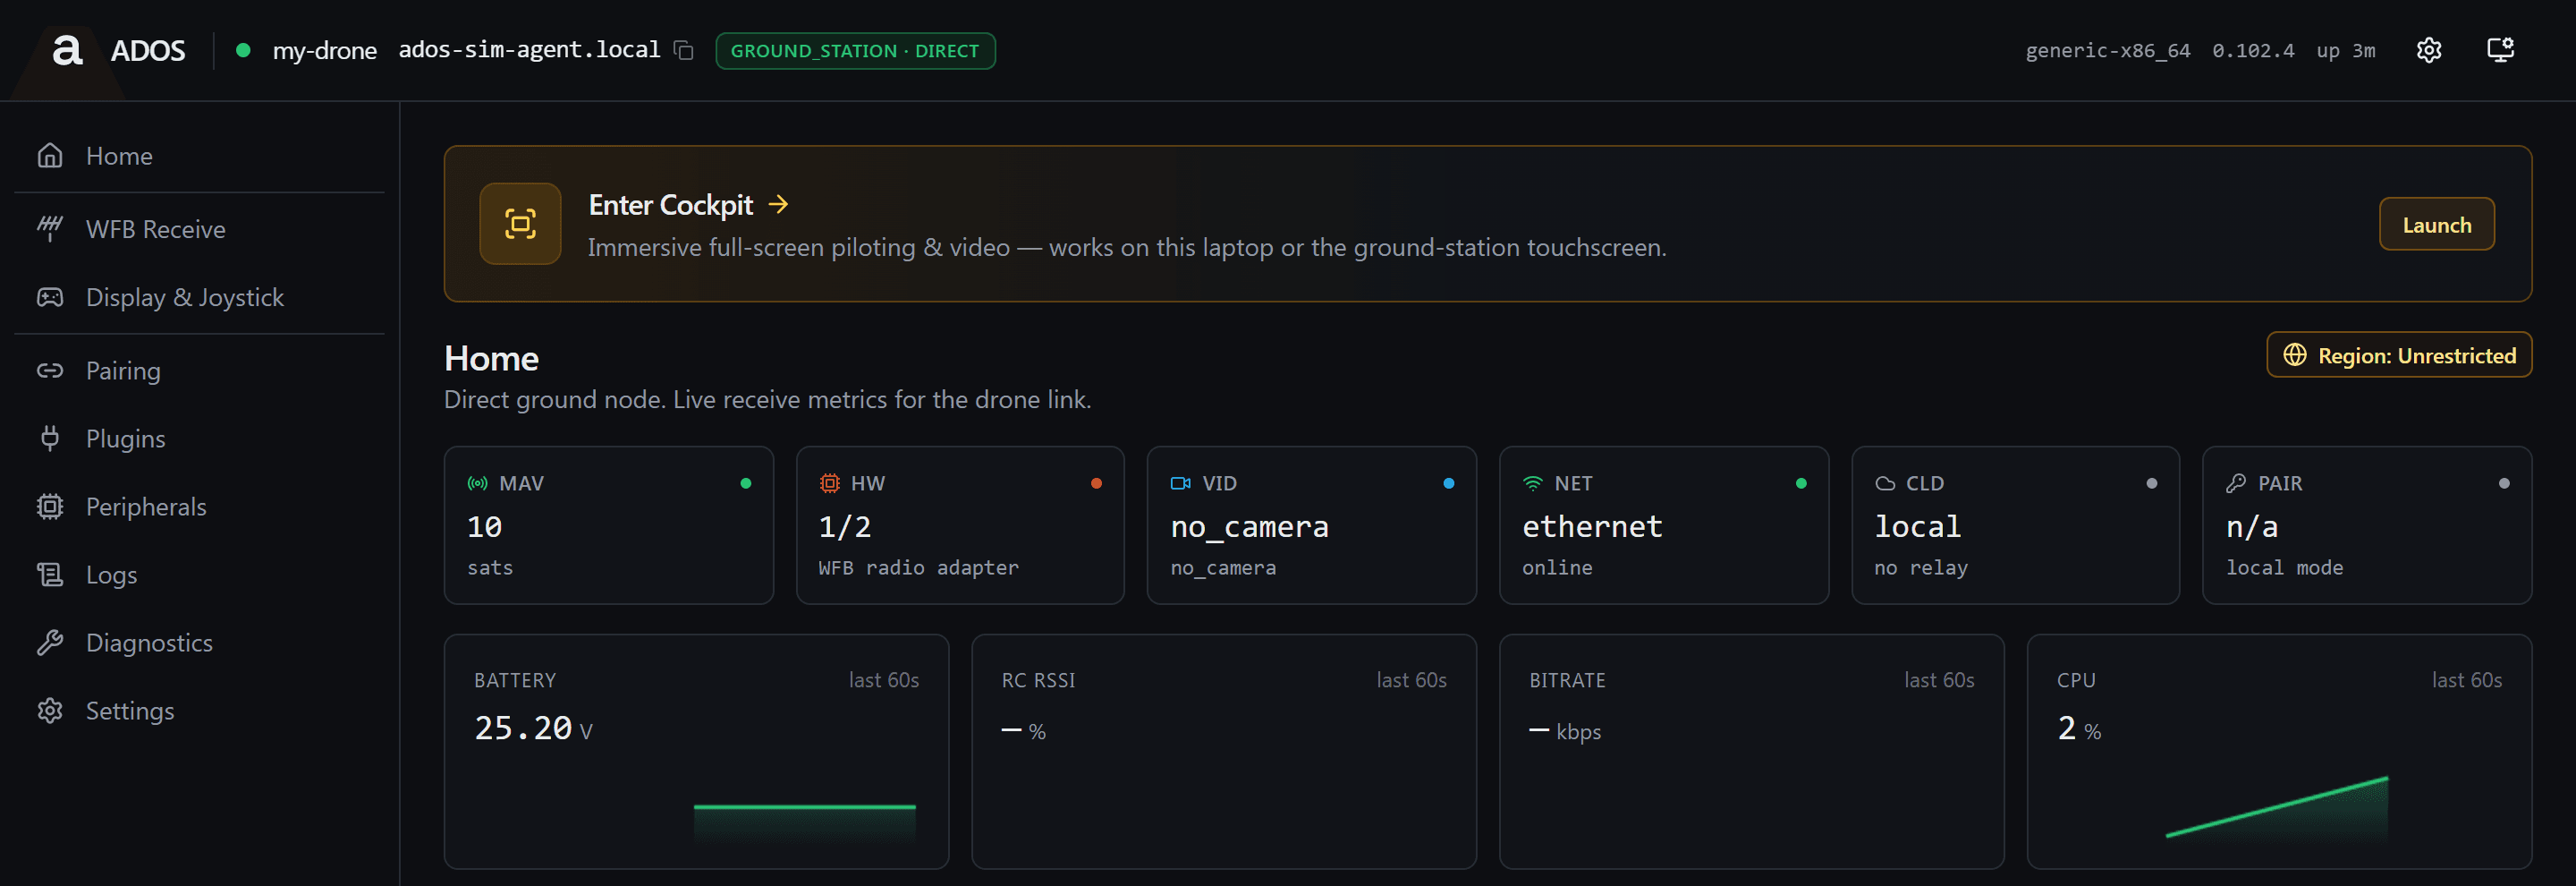
THE ADOS ECOSYSTEM
Four layers. One platform. Any drone.
From the flight computer to the cloud, every layer is open source and designed to work together, or on its own.
Mission Control works with any MAVLink drone today. The agent runs on Debian or Ubuntu Linux boards, ARM or x86. The board is optional. Together they are one system.
WORKING TODAY
Open to read, ready to fly.
Each of these runs in the current release. The code is on GitHub if you want to see how.
Cockpit
An immersive cockpit where flight behaviors are Skills bound to hotkeys and a gamepad, shown on a bottom Skill Bar.
Learn more →ADOS Atlas
Capture-to-reconstruction world model. Drones capture pose-tagged keyframes, a compute node builds splats, point clouds, and mesh.
Learn more →Extension ecosystem
Signed agent plugins and sandboxed ground-station panels from one manifest. Same hardware, different mission, just install an extension.
Learn more →Four firmware families
ArduPilot, PX4, Betaflight, and iNav out of the box. 72 MAVLink decoders plus MSP v1/v2 for Betaflight and iNav. Not locked to one flight stack.
Learn more →MISSION CONTROL
The most capable open ground control station.
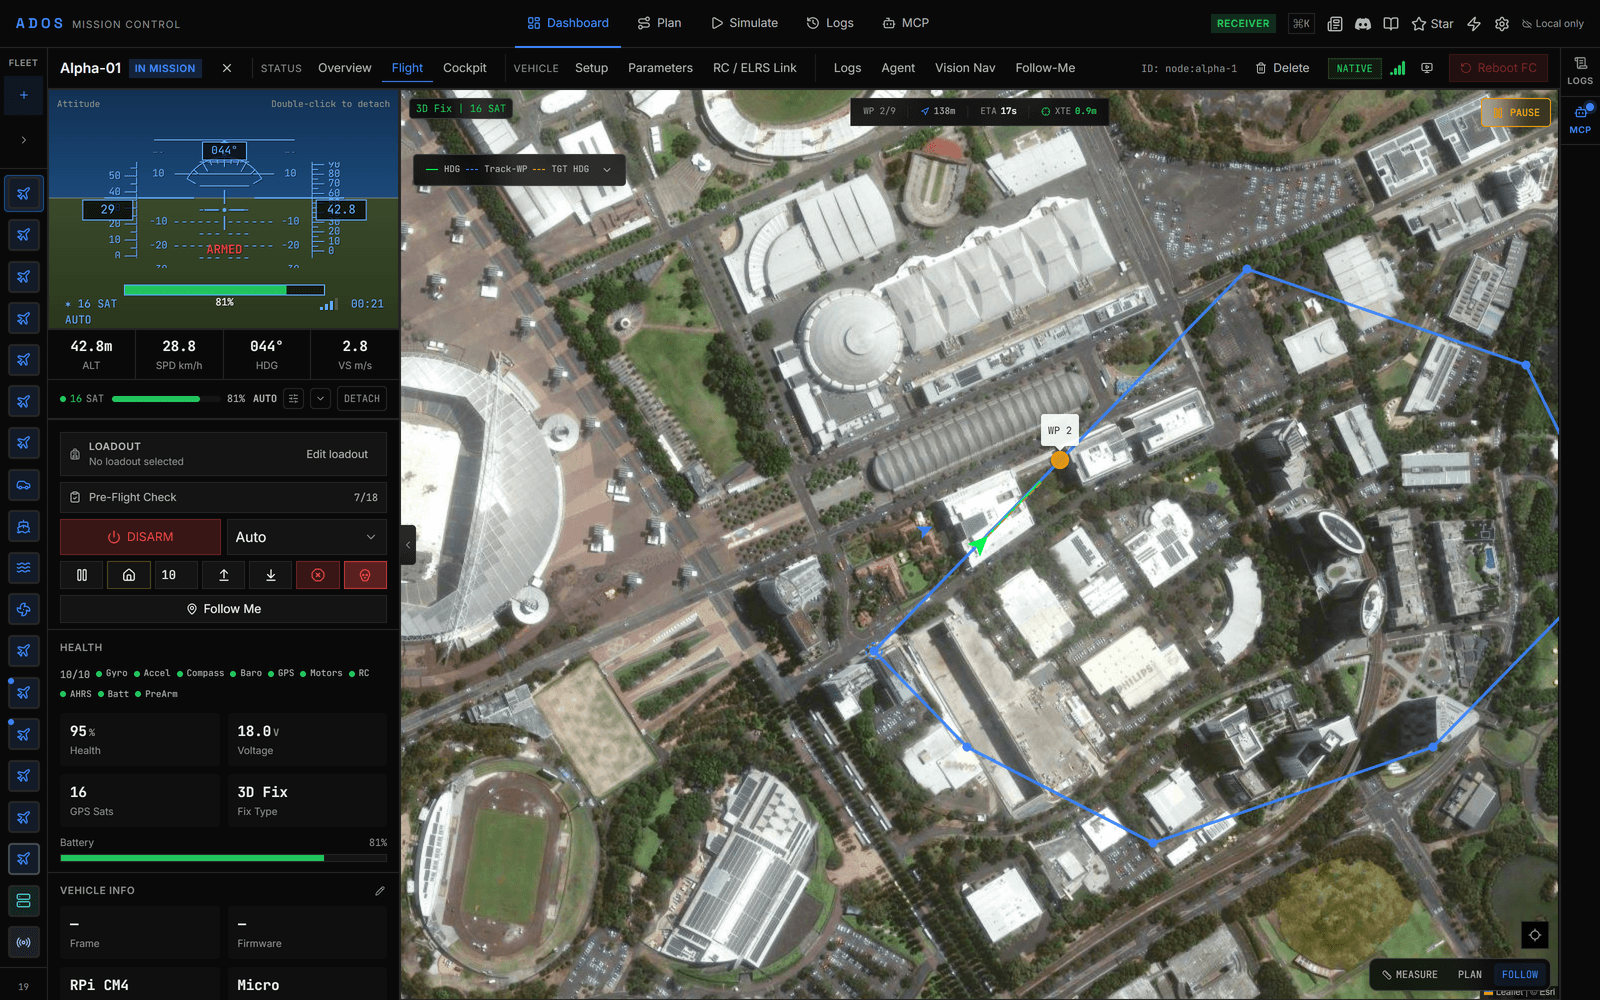
Four firmware stacks. Works offline on local links. Runs in your browser. No install, no licence fee.
- +9 mission pattern generators, plus terrain-relative altitudes
- +3D simulation on a Cesium globe with real terrain and flight replay
- +AI-assisted PID tuning from flight logs
- +WebSerial firmware flashing, no external tools
- +Demo drones built in, zero hardware required
- +Works offline over USB and local links, with cached map tiles
DRONE AGENT
Turn any Linux board into a drone brain.
Companion-computer software that adds video streaming, cloud connectivity, autonomous missions, and AI inference to any MAVLink drone.
- +Runs on a Raspberry Pi Zero 2 W through a Jetson Orin Nano, from 512 MB RAM (1 GB+ for video)
- +MAVLink proxy routes telemetry to multiple ground stations
- +WFB video link on 5.8 GHz with FEC, rated to 50 km line-of-sight
- +MQTT cloud relay, no port forwarding needed
- +Local setup webapp and on-box status cockpit
- +systemd-managed services with per-service sandboxing and resource limits
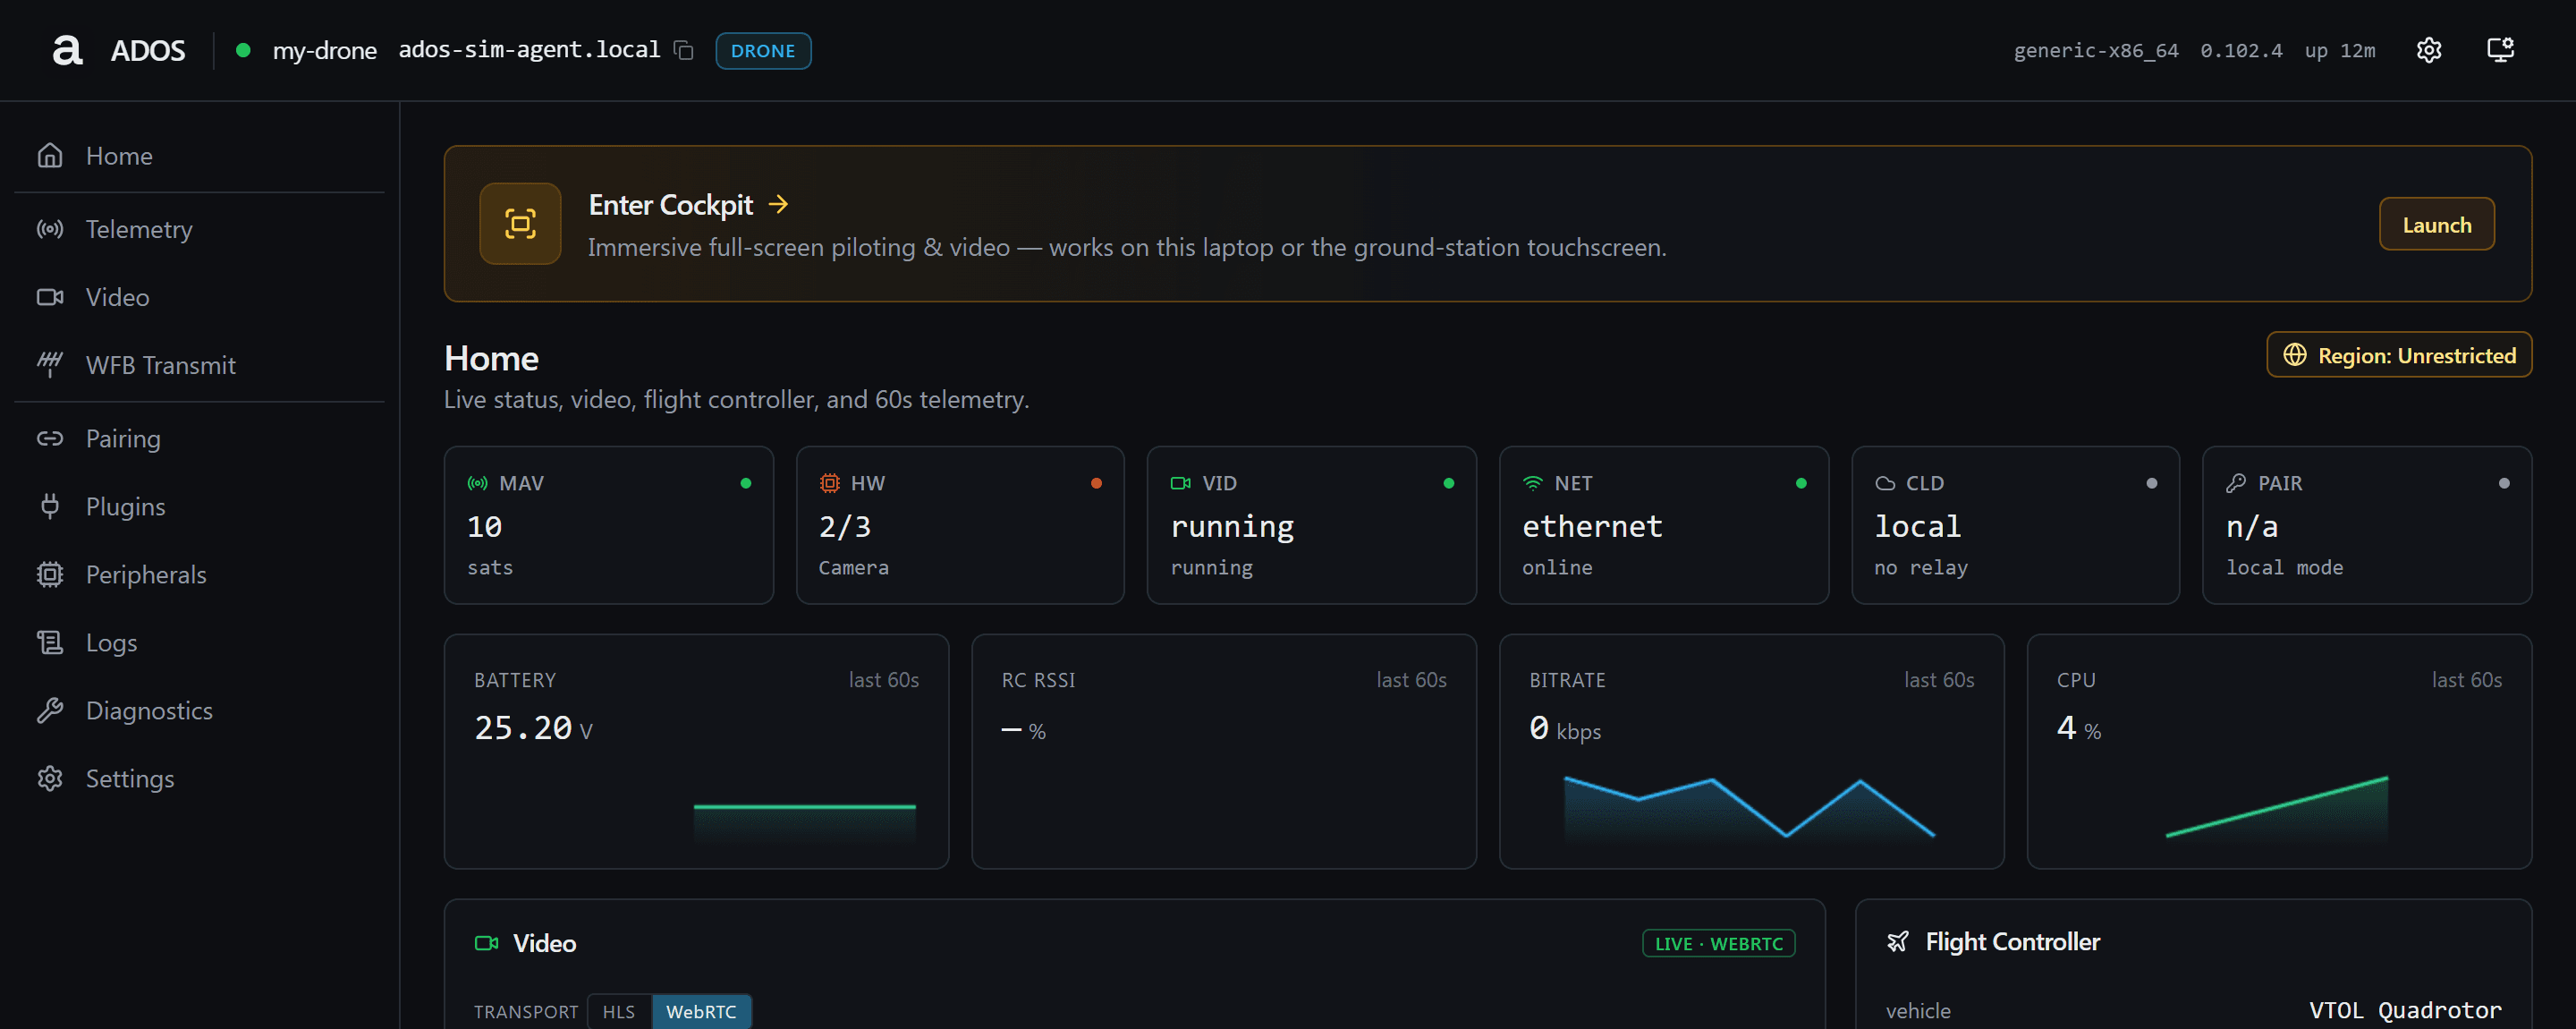
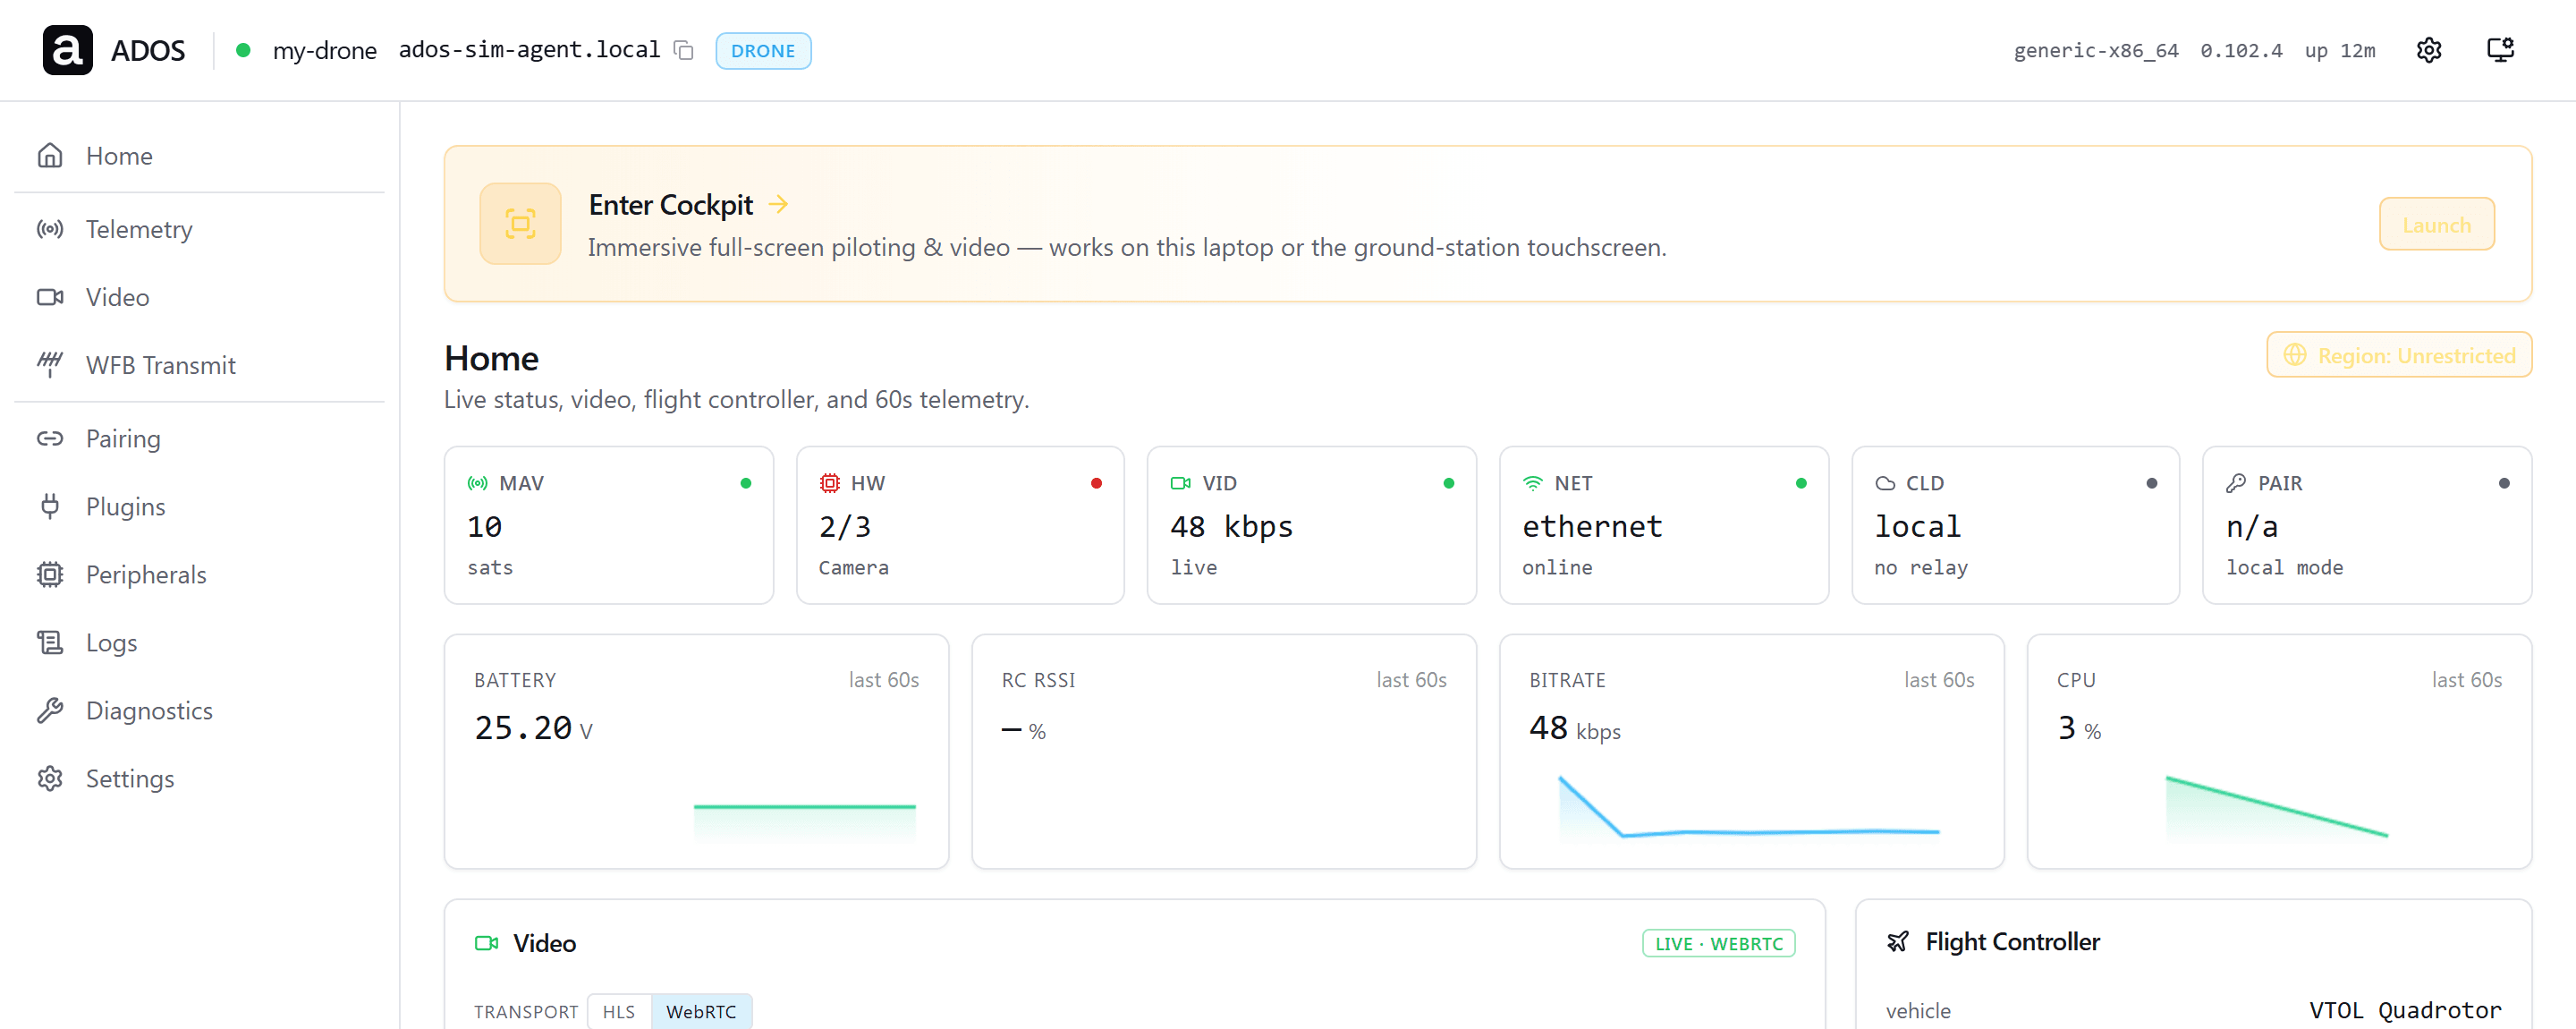
▌ ADOS ados-x · drone v0.99.108 · refreshed 12:00:00 UTC ● HEALTHY paired · local mode ╭ ▌ Links ───────────────────────────────────────────╮╭ ▌ Autopilot ───────────────────────────────────────────────────╮ │Console ││● FC connected LOITER ARMED │ │Setup & dashboard in a browser, on this LAN. ││██████████████████████████battery 79% █████████████ │ │➜ http://ados-x.local:8080/setup ● ││▆▆▆▆ │ │➜ http://192.168.1.5:8080/setup ││GPS 3D sats 14 alt 15.0 m │ │ ││ ▂▅█ │ │Connect to GCS ││ │ │Add this drone to Mission Control - paste one of ││ │ │these into the Add-a-Node card (LAN pairing). │╰────────────────────────────────────────────────────────────────╯ │➜ http://ados-x.local:8080 ● │╭ ▌ Video ───────────────────────────────────────────────────────╮ │➜ http://192.168.1.5:8080 ││● running │ │ │╰────────────────────────────────────────────────────────────────╯ │Ground control │╭ ▌ Link ────────────────────────────────────────────────────────╮ │Conventional MAVLink over TCP / WebSocket for a ││cloud not configured │ │third-party GCS - tcp://…:5760 (QGC / Mission ││remote disabled │ │Planner desktop), ws://…:8765/ (browser GCS). ││hotspot off │ │➜ ws://ados-x.local:8765/ │╰────────────────────────────────────────────────────────────────╯ │ │╭ ▌ Services ────────────────────────────────────────────────────╮ │Video ││● 2 running ○ 0 stopped │ │Live camera in a browser (WHEP viewer). ││ │ │➜ http://ados-x.local:8889/main/ ● ││ │ │➜ http://192.168.1.5:8889/main/ ││ │ │ ││ │ │Mission Control ││ │ │Open Mission Control to fly this drone. Hosted at ││ │ │command.altnautica.com; a local or self-hosted build││ │ │runs wherever you serve it (e.g. ││ │ │http://localhost:4000). ││ │ │➜ https://command.altnautica.com ││ │ │ ││ │ │Direct IP is most reliable. It works from ││ │ │command.altnautica.com too. ││ │ │The .local (mDNS) name needs a desktop app on the ││ │ │LAN. ││ │ │ ││ │ ╰────────────────────────────────────────────────────╯╰────────────────────────────────────────────────────────────────╯ [d] driver [p] pair [l] logs [a] actions [r] refresh [q] quit v0.99.108 · up to date
THE OPEN LAYER
Where the compute layer lives
Integrated smart-drone makers run their onboard compute layer first-party, and they do it well. Most assembled drones lack that layer entirely. Altnautica builds it as an open layer anyone can extend.
| First-party smart drone | Assembled drone | Altnautica | |
|---|---|---|---|
| Onboard compute | Proprietary onboard compute | None, or a tethered external SBC | Linux companion agent beside any FC |
| Software platform | First-party only, vendor-controlled | Autopilot only, no platform layer | Full stack: agent, GCS, ground station, cloud |
| Video link | In-house digital link | Analog or basic digital, short range | WFB-ng, rated to 50 km LOS, open protocol |
| Licensing | Single-vendor ecosystem | Each brand siloed | Open source, forkable, GPLv3 |
| Customization | Limited to the vendor SDK | Limited | Modify everything |
| AI and autonomy | Yes, vendor-managed | No onboard intelligence | Yes, open and extensible |
Onboard compute
Software platform
Video link
Licensing
Customization
AI and autonomy
FAQ
Frequently asked questions
What is Altnautica?
Altnautica is an open-source, software-defined drone platform. It provides an onboard drone agent, a browser-based ground control station called Mission Control, a ground station, a compute workstation, and cloud fleet management, so you can make almost any drone smart and autonomous.
How do I make an existing drone autonomous?
Add a companion computer running the Altnautica drone agent next to your flight controller, connect them over MAVLink, and control the drone from Mission Control. You keep your existing ArduPilot, PX4, Betaflight, or iNav flight controller and gain autonomy, long-range video, and fleet connectivity in software.
Is there an open-source ground control station?
Yes. Altnautica Mission Control is an open-source, browser-based ground control station for any drone. It runs in the browser with no install and covers fleet telemetry, mission planning, a 3D simulator, deep flight-controller configuration, and an immersive cockpit, all under GPLv3.
What is an open-source alternative to first-party drone platforms?
Altnautica is an open-source, software-defined drone platform that runs on hardware you choose. You get an open ground station, an onboard agent, long-range video, and cloud fleet management that you can inspect, modify, and self-host, working with ArduPilot, PX4, Betaflight, and iNav.
Is Altnautica free and open source?
Yes. Mission Control, the drone agent, the ground agent, and the workstation are free and open source under GPLv3, and the MCP server is MIT. There is no paid edition and no locked features.
Open Source
We publish the software and the protocols.
The ground station, the agent, the extensions, and the protocols are open source, so you own your stack instead of renting it.
Open source. Shipping now.
Try Mission Control in your browser. Join the Discord. Star us on GitHub.
Launch Mission Control