Four ways in. Pick one.
HOW IT FLOWS
Browser to first flight
Open Mission Control
command.altnautica.com, no install
Install the agent
One command on the companion board
Pair
Add the node by hostname over the LAN
Fly
Telemetry, video and commands in one tab
- Open Mission Control: command.altnautica.com, no install
- Install the agent: One command on the companion board
- Pair: Add the node by hostname over the LAN
- Fly: Telemetry, video and commands in one tab
1 / NO INSTALL
Mission Control in a browser tab
The ground control station is a web app. Open it, plug a flight controller into USB, and it talks MAVLink or MSP over WebSerial. No account is required to fly a local vehicle.
- URL
- command.altnautica.com
- Install
- none
- Account
- not needed to fly locally
- License
- GPL-3.0-only
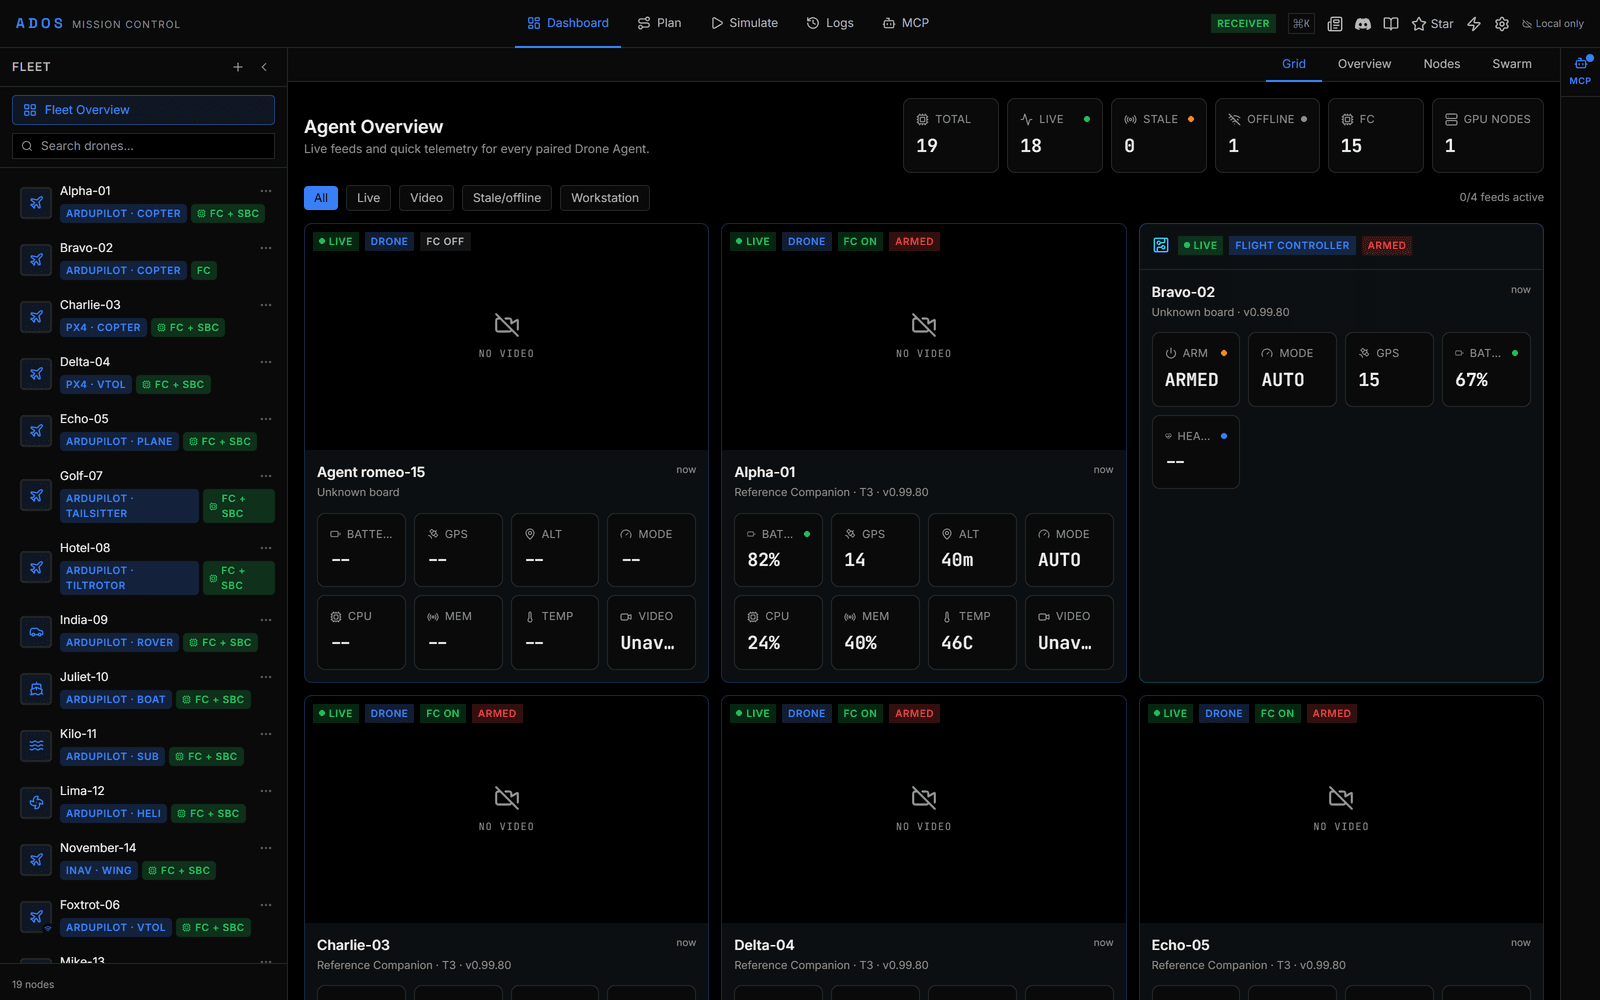
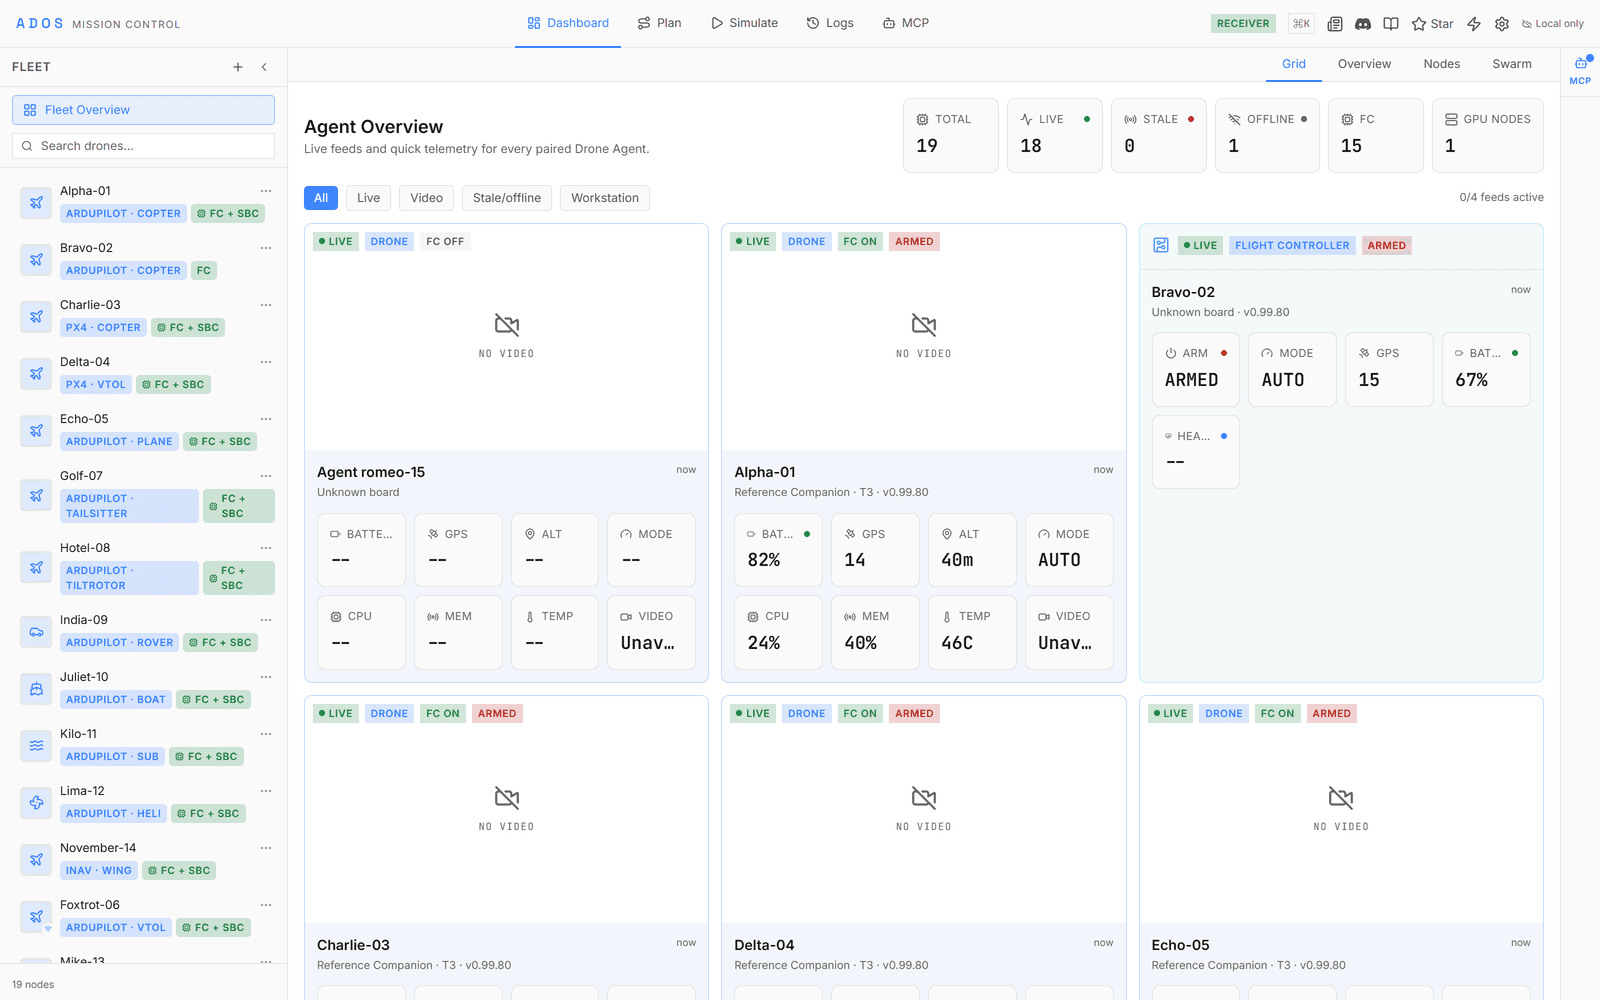
Prefer to run it yourself? The same app self-hosts with one guided deployer, together with a self-hosted Convex backend, MQTT and the video relay. See the self-hosting guide.
$# Stand up the whole cloud stack on your own box:
curl -sSL https://raw.githubusercontent.com/altnautica/ADOSMissionControlGCS/main/tools/deploy/deploy.sh | sh
2 / THE AGENT
One command on the companion board
One installer serves every node role. It fetches a prebuilt ARM64 installer from GitHub Releases, checks its SHA-256 and its release signature before running anything as root, installs the services, and reboots once only if the hardware setup needs it.
$# On the drone (default profile):
curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh | sudo bash

# On the ground station:
curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh \
  | sudo bash -s -- --profile ground-station

# Upgrade an existing node in place:
curl -sSL https://raw.githubusercontent.com/altnautica/ADOSDroneAgent/main/scripts/install.sh \
  | sudo bash -s -- --upgrade
Four profiles, one installer
--profile takes drone, ground-station, workstation or compute. Omit it and a fresh box installs the drone profile. A box that already has a profile keeps it across an upgrade.
On a Mac it builds from source
There is no prebuilt macOS binary, so the same script detects Darwin and compiles the workstation or compute profile with cargo into per-user launch agents. Run it without sudo; it refuses to run as root on macOS. Needs the Rust toolchain and git.
- CPU architecture
- ARM64 (aarch64); x86_64 from a local build
- Operating system
- Debian-family Linux, systemd
- Privileges
- root (sudo)
- Python
- 3.11+, or provisioned
The one-line bootstrap ships prebuilt binaries for ARM64 only. On an x86_64 Linux box it stops with a clear error and points you at the source build: compile the installer with cargo and run it with --channel edge --artifacts, as shown under For contributors below. Any other architecture is refused rather than half-installed. If no suitable Python is on the box the installer provisions a private CPython 3.11 instead of failing.
3 / DESKTOP
Mission Control as a desktop app
The same GCS wrapped for the desktop, built from the tagged release. Useful when you want USB serial and a local window instead of a browser tab.
The macOS builds are not code-signed or notarized, so Gatekeeper will ask you to allow them on first launch and updates are a manual download. Grab the assets from the release page.
4 / ANDROID
Build the Android ground station
The native Android GCS is real code you can build and fly today, but there is no signed release and no store listing yet, so the only honest install path is a source build.
$git clone https://github.com/altnautica/ADOSAndroidGCS
cd ADOSAndroidGCS
./gradlew assembleDebug
# app/build/outputs/apk/debug/app-debug.apk
Needs JDK 17 and Android SDK 35. The app targets ARM64 devices on Android 10 or newer. More on what it does, and what it does not do yet, on the Android ground station page.
VERIFY
Check the install actually worked
The agent ships its own diagnostics. Run these on the node over SSH or on its console before you take anything to a field. Plain ados opens the terminal status page shown here.
$ados                 # the terminal status page
ados version         # works even when the service is down
ados status --json   # the same status as JSON
ados diag video      # a per-hop video verdict
ados diag link       # deaf, mis-keyed, jammed or healthy
ados logs tail       # follow the Black Box store
A healthy first boot shows a reachable setup URL, a flight controller with a live heartbeat, and the services running. If video is the problem, ados diag video names the hop that broke rather than making you read logs. The Black Box log store is off by default, so the system journal is the log of record; switch the store on and it survives a reboot and stays readable with the network down.
▌ADOS my-drone DRONE ● FC ArduPilot DISARMED STABILIZE ⇄ local 12:00:00 1 Overview 2 Vehicle 3 Link 4 Video 5 Params 6 Extensions 7 Logs 8 System 9 Settings ╭──────────────────────────────────────────────────────────────────────────────────────────────────────────────────────╮ │● HEALTHY │ │paired · cloud relay │ │╭ ▌ Links ──────────────────────────────────────────╮╭ ▌ Autopilot ──────────────────────────────────────────────────╮│ ││Console ││● ArduPilot connected STABILIZE DISARMED ││ ││Setup & dashboard in a browser, on this LAN. ││/dev/ttyACM0 · 115200 ││ ││➜ http://my-drone.local:8080/setup ● ││██████████████████████████battery 92% ████████████████████ ││ ││➜ http://192.168.1.50:8080/setup ││▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇▇ ││ ││ ││GPS 3D sats 14 alt 0.3 m ││ ││Connect to GCS ││ ││ ││Add this drone to Mission Control - paste one of ││ ││ ││these into the Add-a-Node card (LAN pairing). │╰───────────────────────────────────────────────────────────────╯│ ││➜ http://my-drone.local:8080 ● │╭ ▌ Video ──────────────────────────────────────────────────────╮│ ││➜ http://192.168.1.50:8080 ││● running ││ ││ │╰───────────────────────────────────────────────────────────────╯│ ││Ground control │╭ ▌ Link ───────────────────────────────────────────────────────╮│ ││Conventional MAVLink over TCP / WebSocket for a ││cloud paired (https://command.altnautica.com) ││ ││third-party GCS: tcp://…:5760 for a desktop ground ││remote disabled ││ ││station, ws://…:8765/ for a browser GCS. ││hotspot off ││ ││➜ tcp://my-drone.local:5760 ● │╰───────────────────────────────────────────────────────────────╯│ ││➜ ws://my-drone.local:8765/ │╭ ▌ Services ───────────────────────────────────────────────────╮│ ││➜ tcp://192.168.1.50:5760 ││● 11 running ○ 0 stopped ││ ││➜ ws://192.168.1.50:8765/ ││hardware 4 ok ││ ││ ││ ││ ││Video ││ ││ ││Live camera in a browser (WHEP viewer). ││ ││ ││➜ http://my-drone.local:8889/main/ ● ││ ││ ││➜ http://192.168.1.50:8889/main/ ││ ││ ││ ││ ││ ││Mission Control ││ ││ ││Open Mission Control to fly this drone. Hosted at ││ ││ ││command.altnautica.com; a local or self-hosted │╰───────────────────────────────────────────────────────────────╯│ ││build runs wherever you serve it (e.g. │╭ ▌ Sensors ────────────────────────────────────────────────────╮│ ││http://localhost:4000). ││sensors imu 400/400 Hz · gnss 10/10 Hz · camera 30/30 Hz ││ │╰───────────────────────────────────────────────────╯╰───────────────────────────────────────────────────────────────╯│ ╰──────────────────────────────────────────────────────────────────────────────────────────────────────────────────────╯ paired · cloud relay ^K palette · a actions · ? help · q quit v0.106.3
FOR CONTRIBUTORS
Install binaries you built yourself
Working on the agent? The installer will take your local build instead of the release.
$sudo ados-installer --upgrade --profile drone --channel edge --artifacts /tmp/stageEach file in the directory is named for its service and needs a matching .sha256 beside it; any service the directory does not carry still comes from the release. It requires the edge channel and is refused on stable, because a locally built binary has no signature the stable channel can verify. Linux only.
NEXT